
The Foundations of Engineering II group finished off their year with an exciting capstone project: design, build, and program a bomb disposal robot, such as that used by special tactical groups around the world.
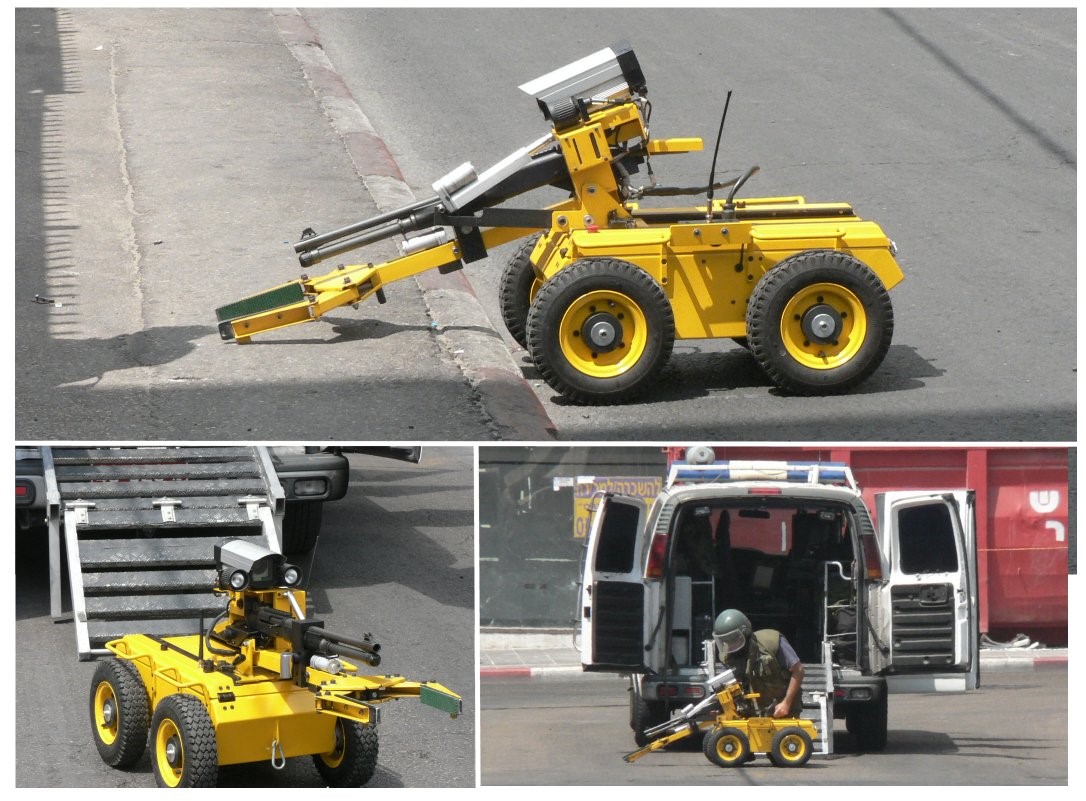 |
A real bomb disposal robot, complete with camera, manipulator claw, and disruptor |
(One quick word needs to be said from the outset: this project was carefully and sensitively planned. It was made clear to the students that this was not making light of terrorism, explosives, or other acts of crime. Rather, this was another chance to show how our engineering skills can be used to create things that combat pain and suffering and sinful acts; such robots actually keep humans out of the way of harm as much as possible.)
The students were split into three groups at random, and they set about sketching their designs, in accordance with the design brief. Each robot was required to move through the following phases:
- Power up and deploy, moving down a ramp.
- Make its way to a classroom with a “locked door” (it was made of wood and foamboard!).
- Break through the door and enter the hostile zone.
- Locate the active “bomb”, and take it back through the door to a safe location outside.
- Neutralize the bomb with a built-in disruptor.
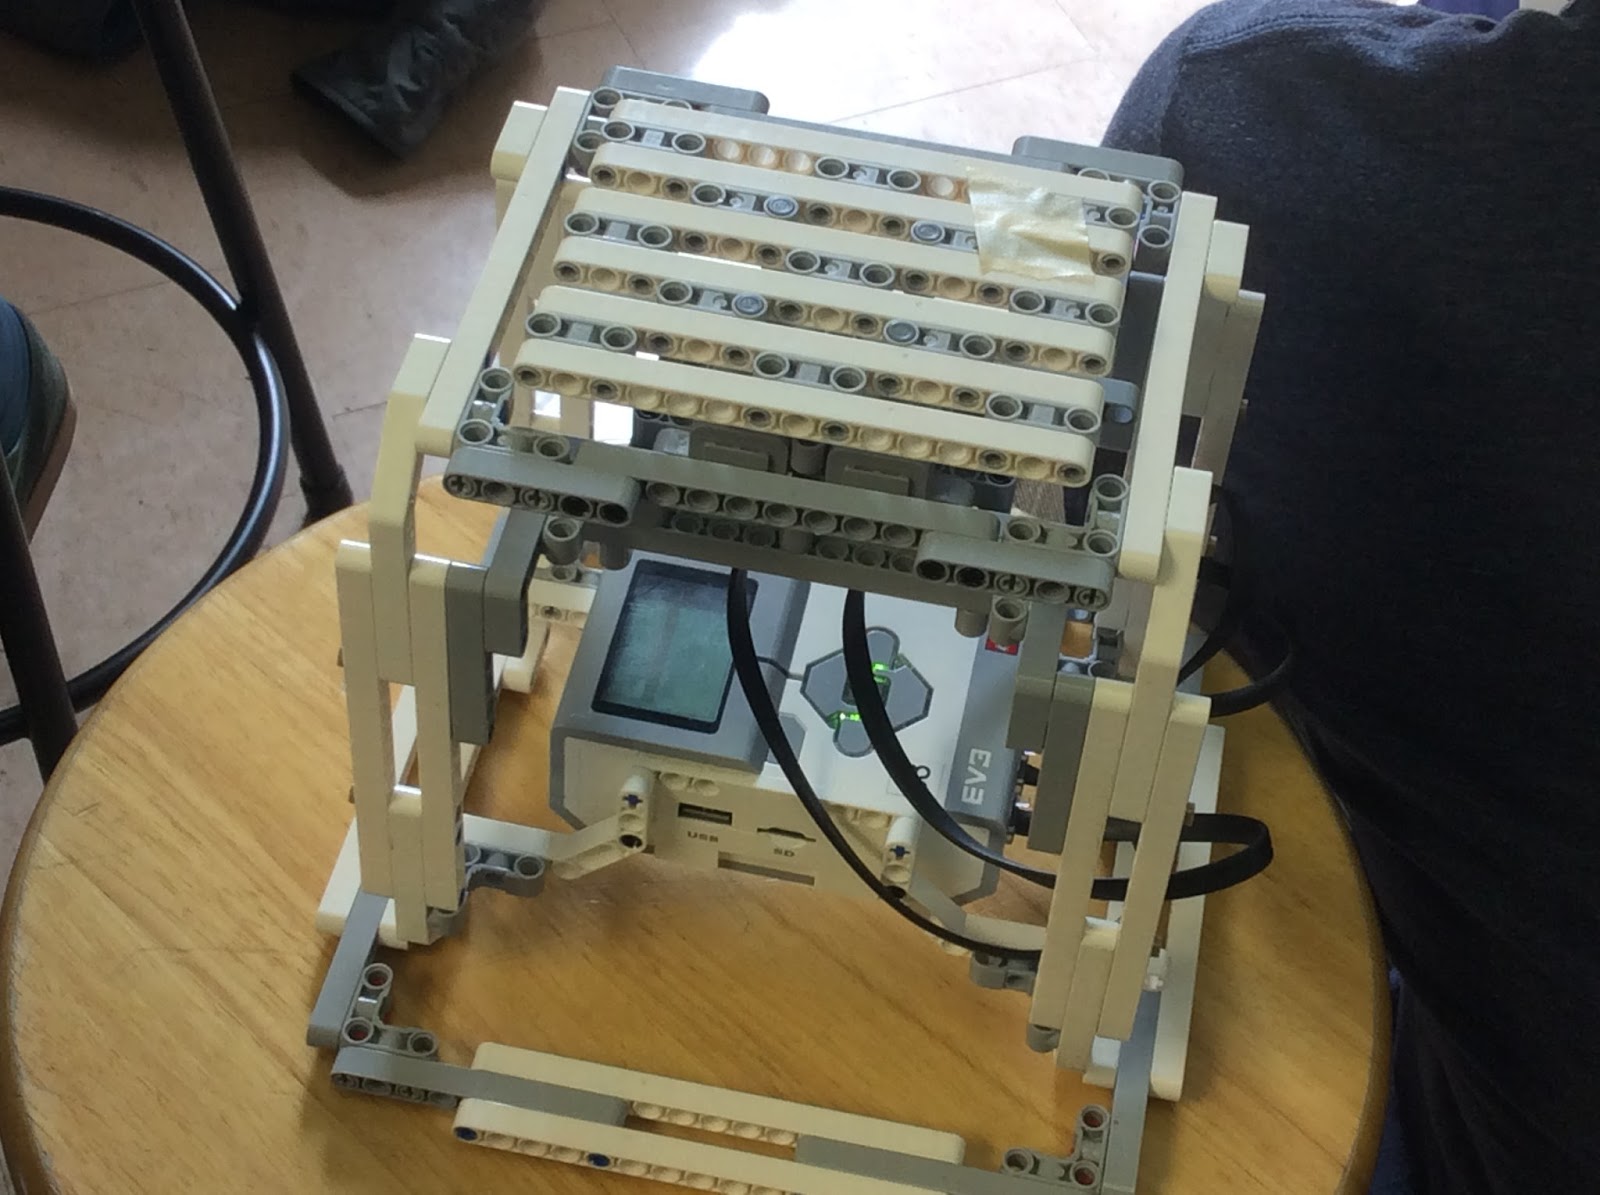 |
The “bomb”, made out of LEGO Mindstorms pieces, with a touch- sensitive touch plate on top |
Within a matter of days, the three teams had settled on their designs, and were putting together large, strong bases for their robot. Needless to say, there were no instructions to follow! Ingenuity, teamwork, and a little bit of teacher input were the tools at hand.
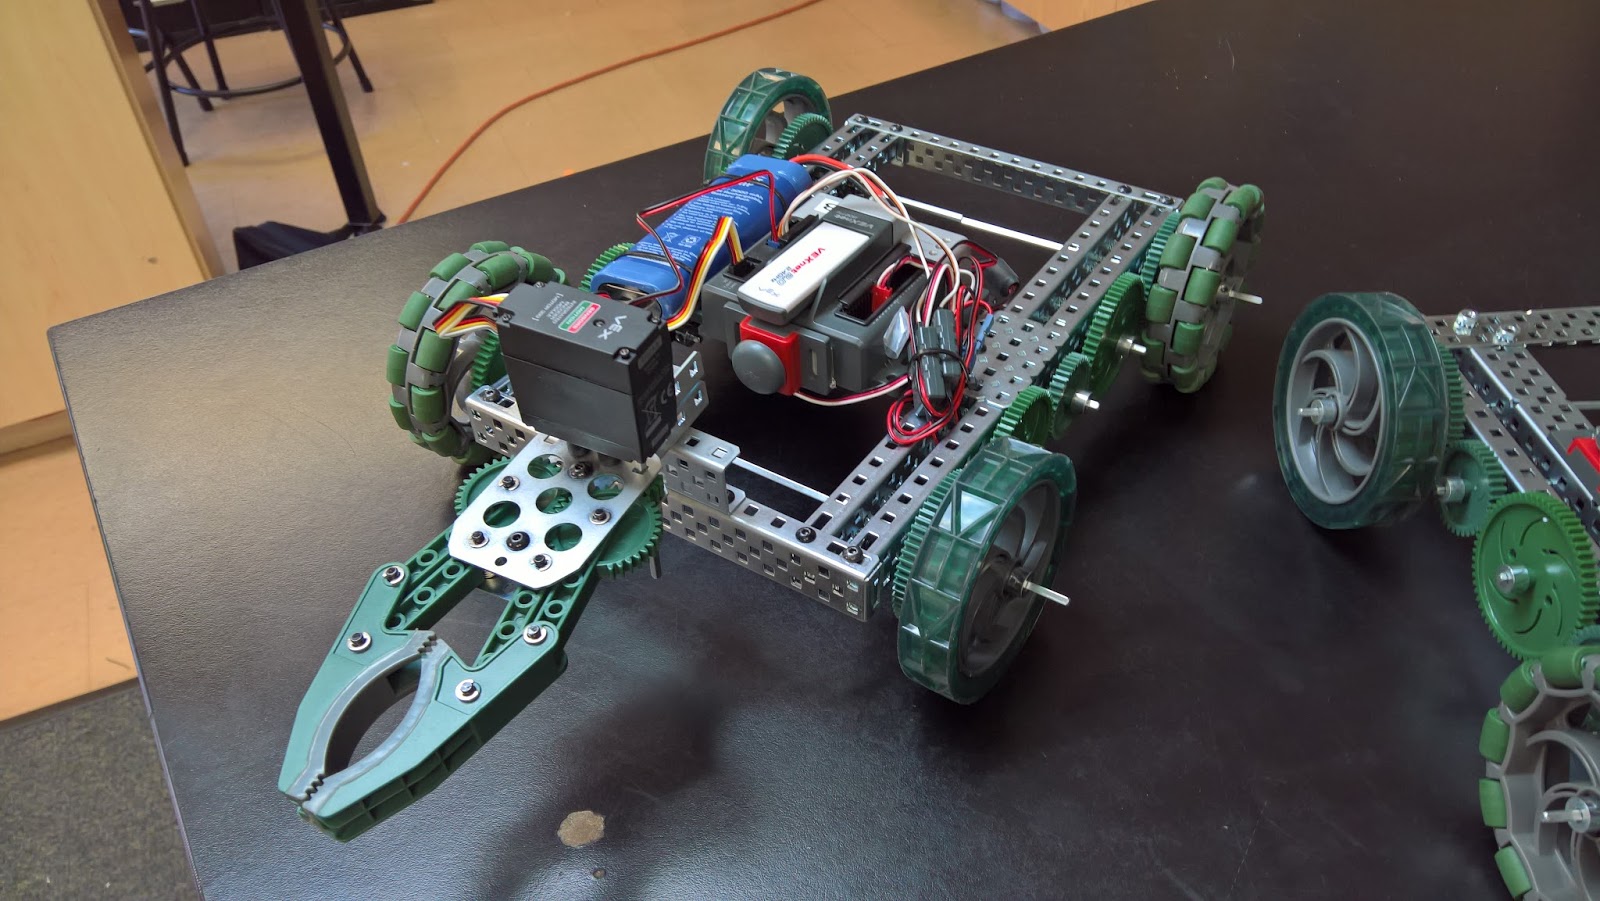 |
| Eva’s team’s early design, with base and claw in place |
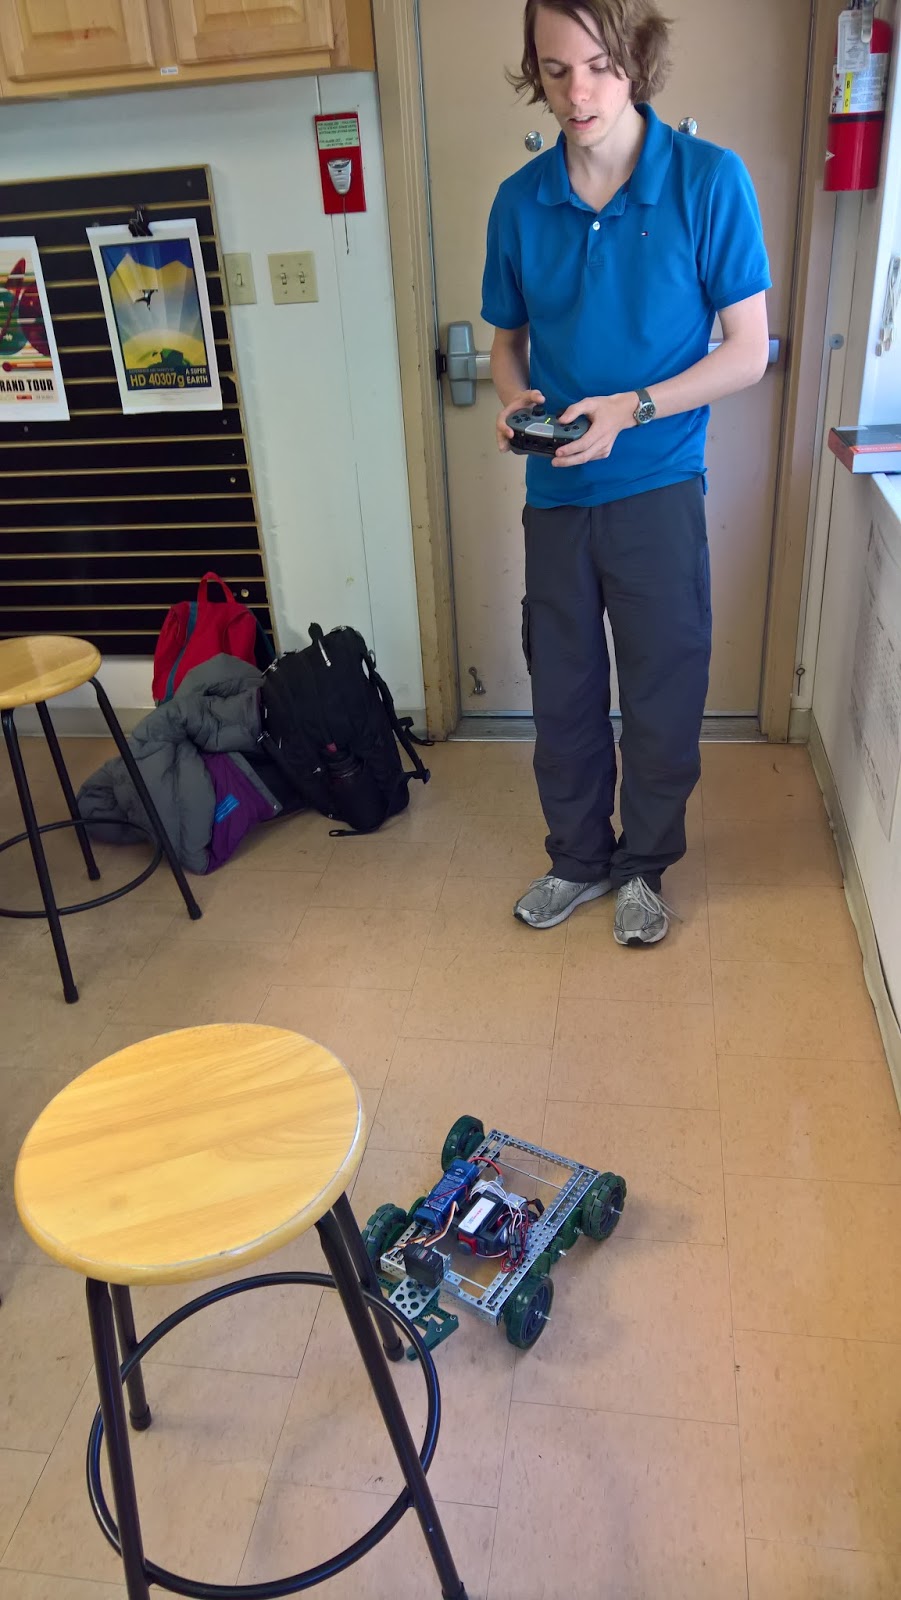 |
Colby demonstrates the surprising strength of the robot, dragging a stool across the room! |
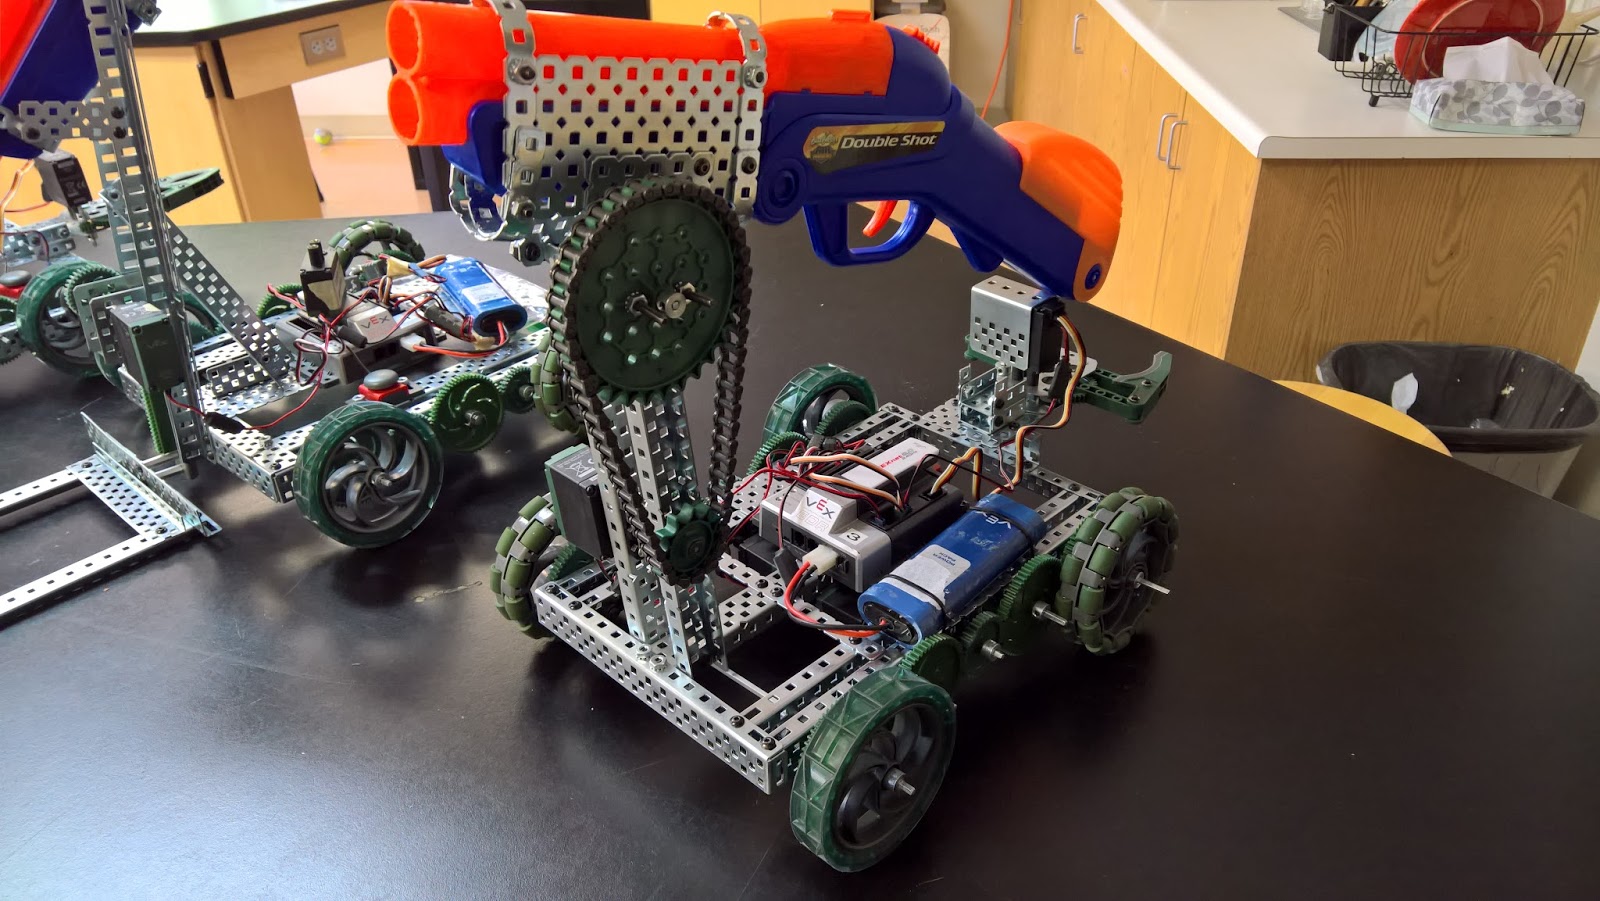 |
An almost-final version, with the disruptor now mounted; note the chain drive to pivot and aim the disruptor |
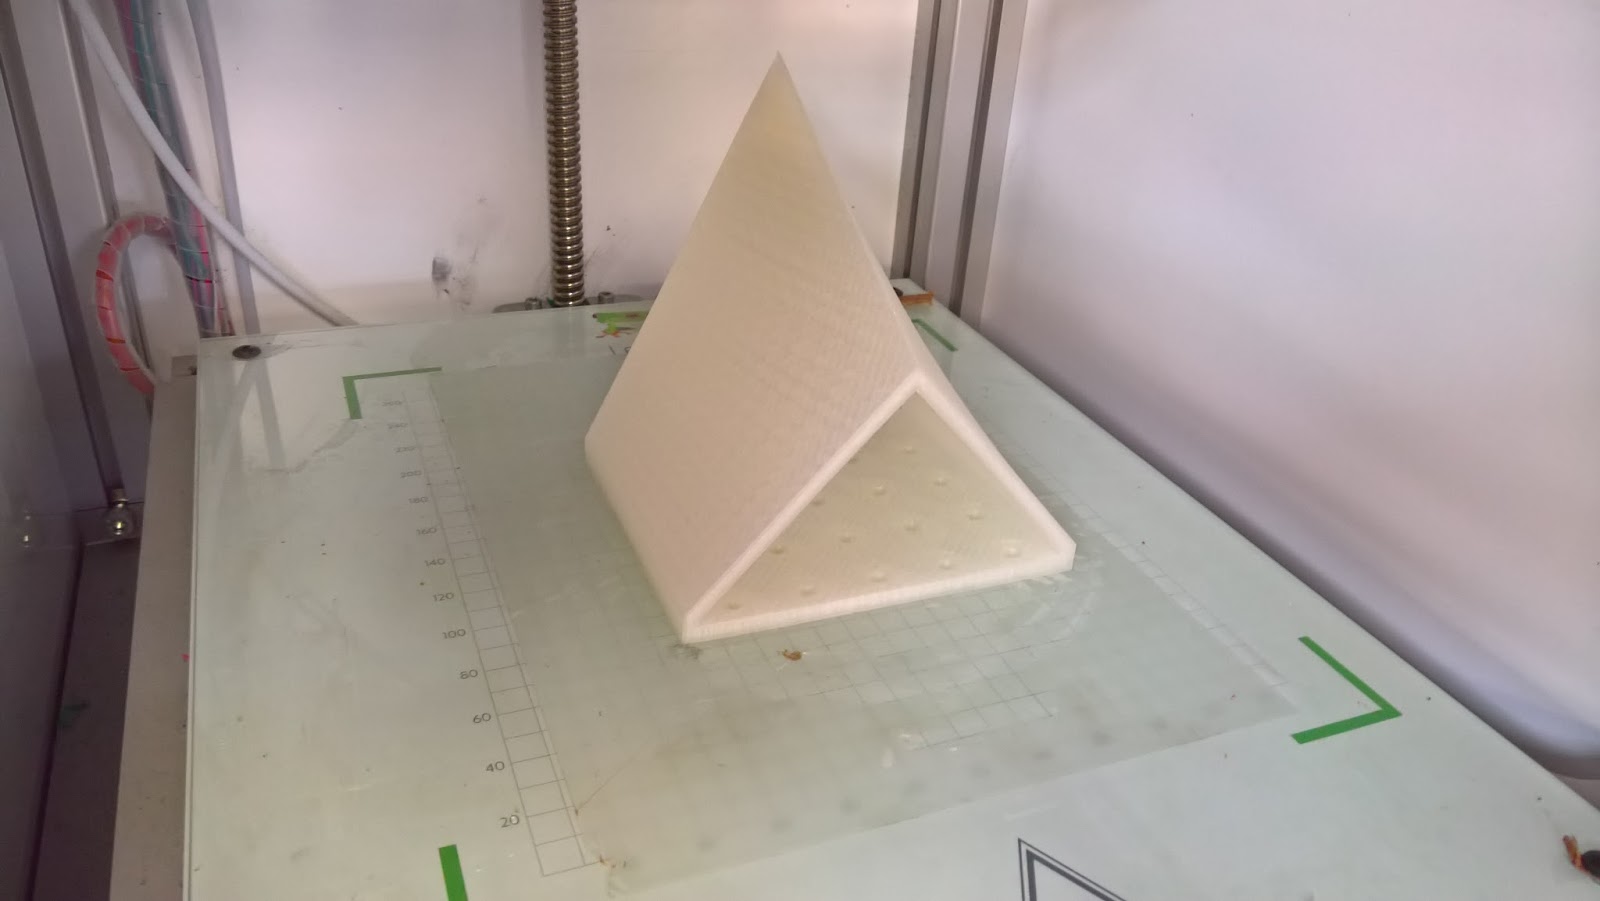 |
Todd’s “cattle catcher” came out perfectly first time, made with a simple but beautiful loft between two triangles |
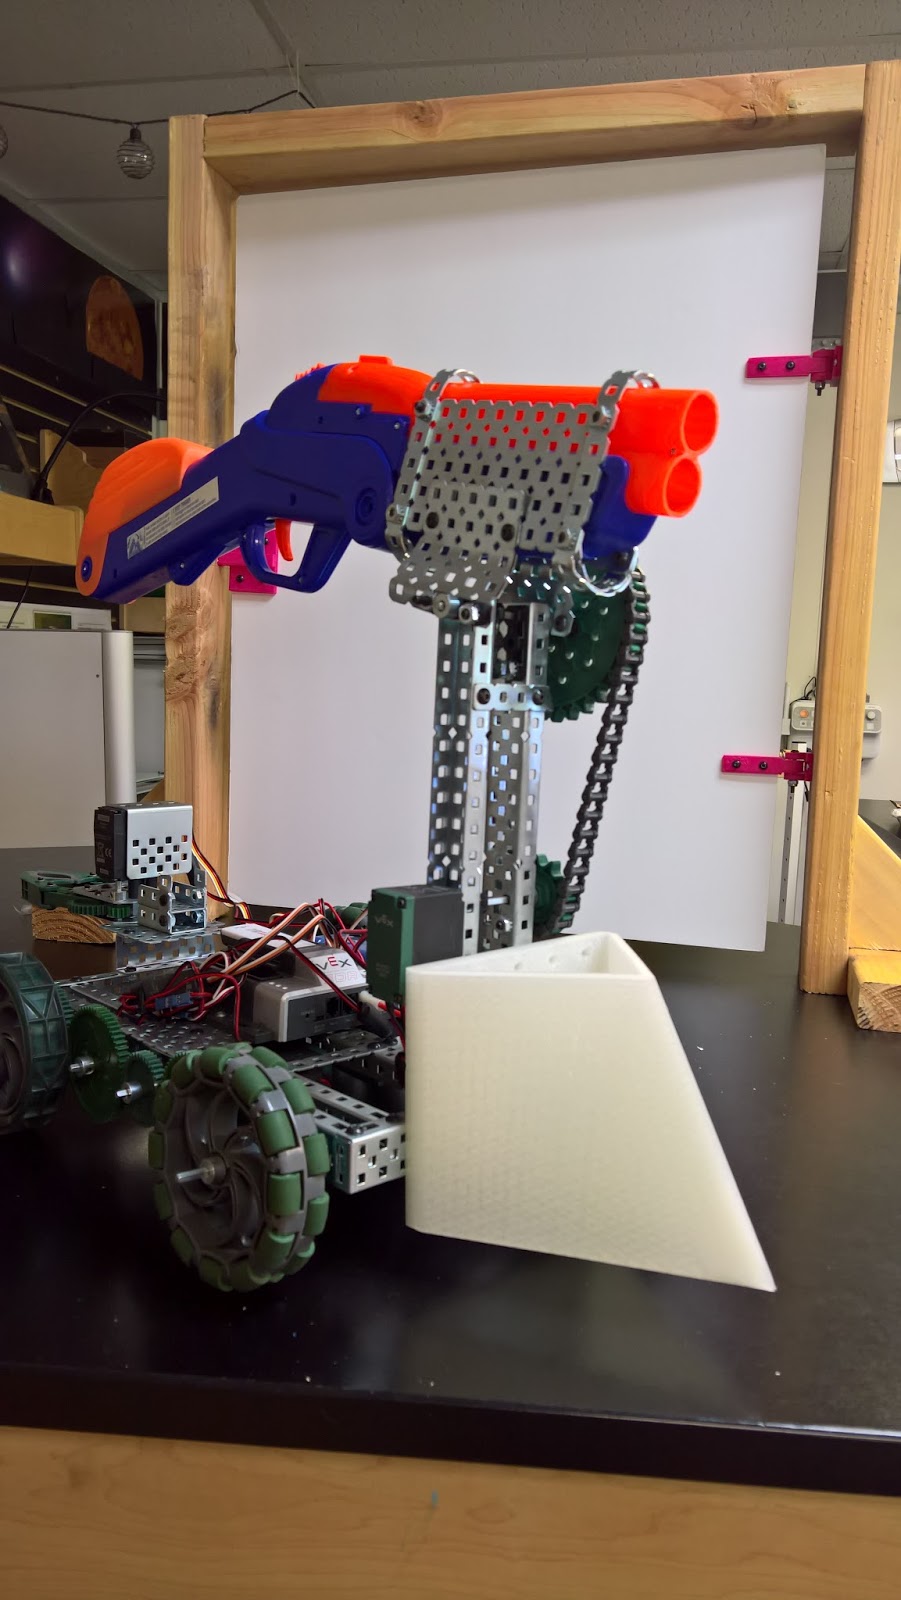 |
The finished product, ready and raring to go! |
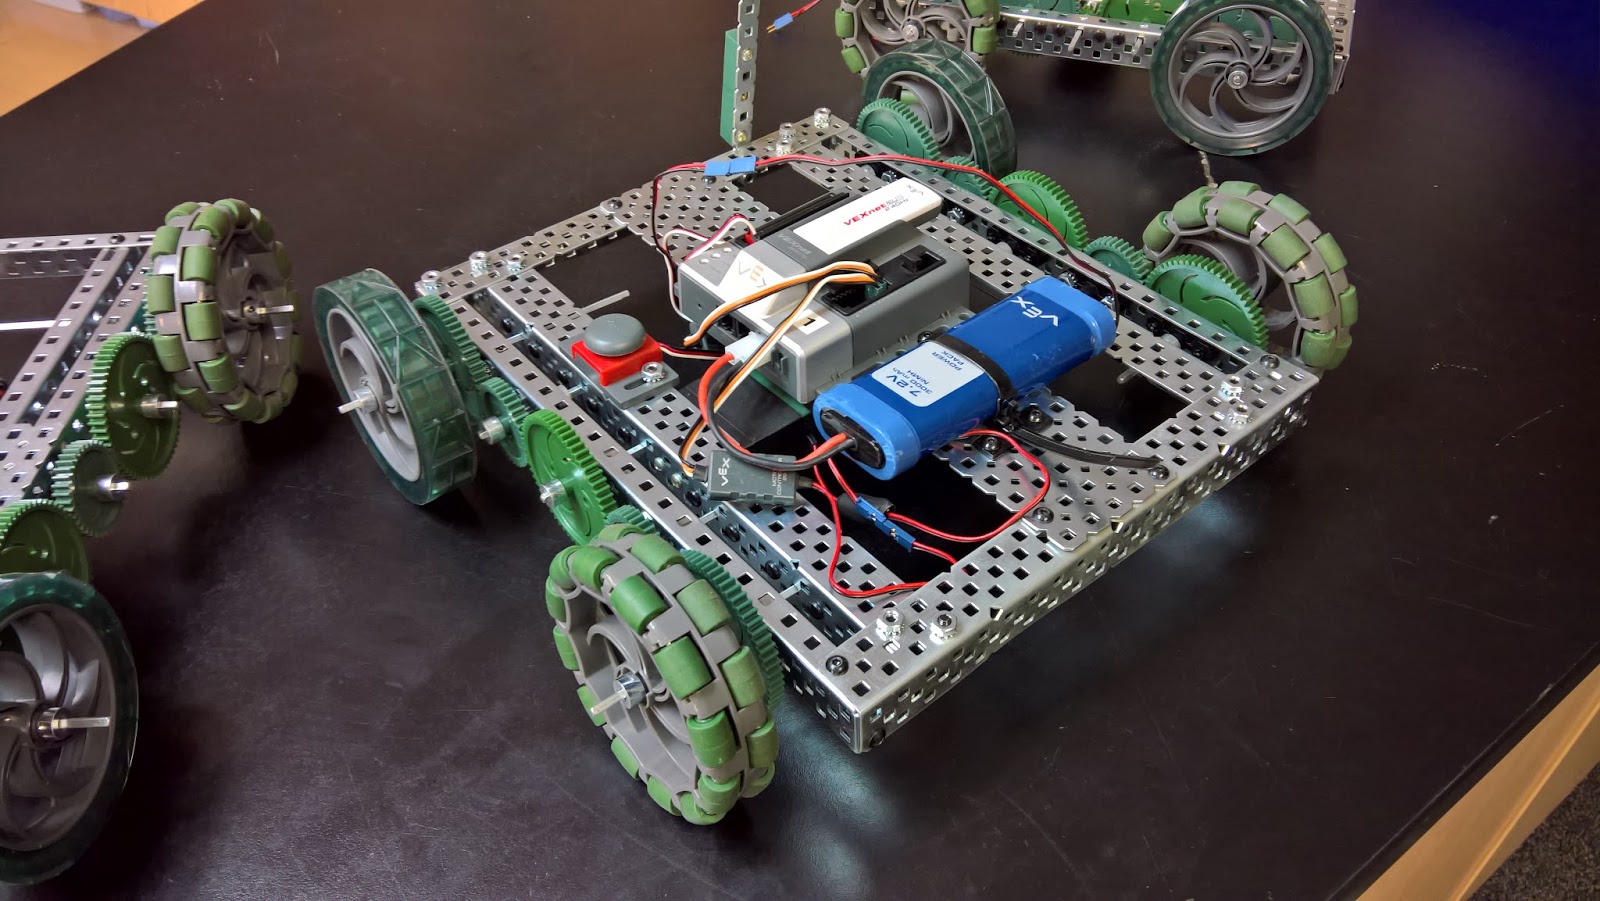 |
An early version of Alena’s team’s solution, with a solid base constructed (note the “omni-wheels” that allow the robot to more easily pivot left and right) |
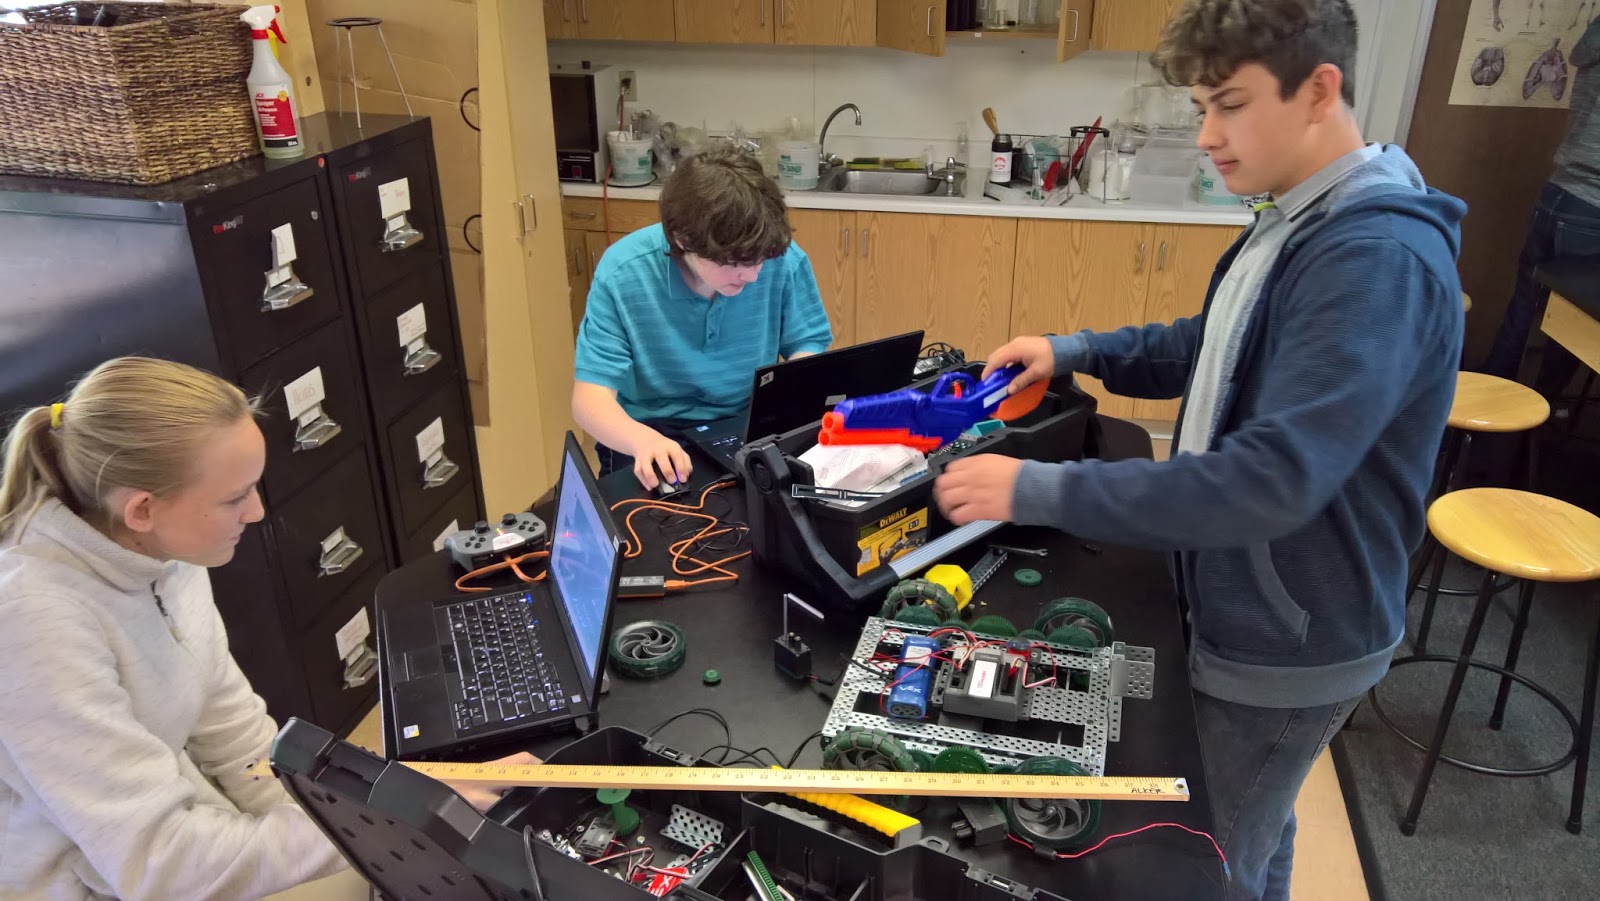 |
Alena works on her CAD pieces, Jakob writes code, and Samy “checks the disruptor for functionality” |
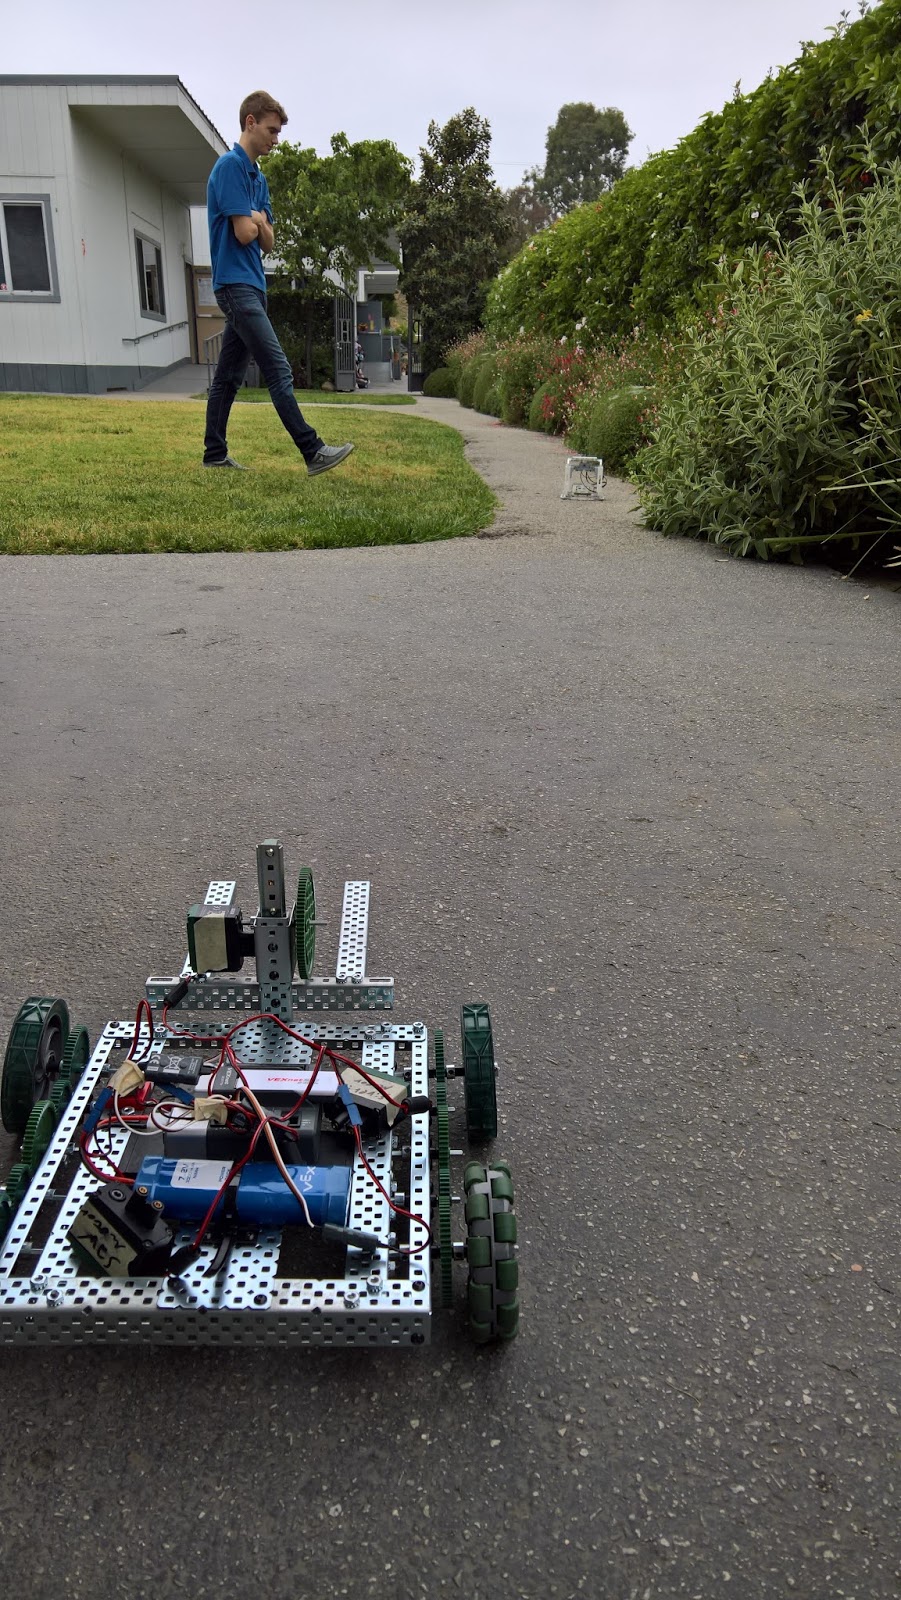 |
An early outdoor test; note the addition of a forklift system on the front |
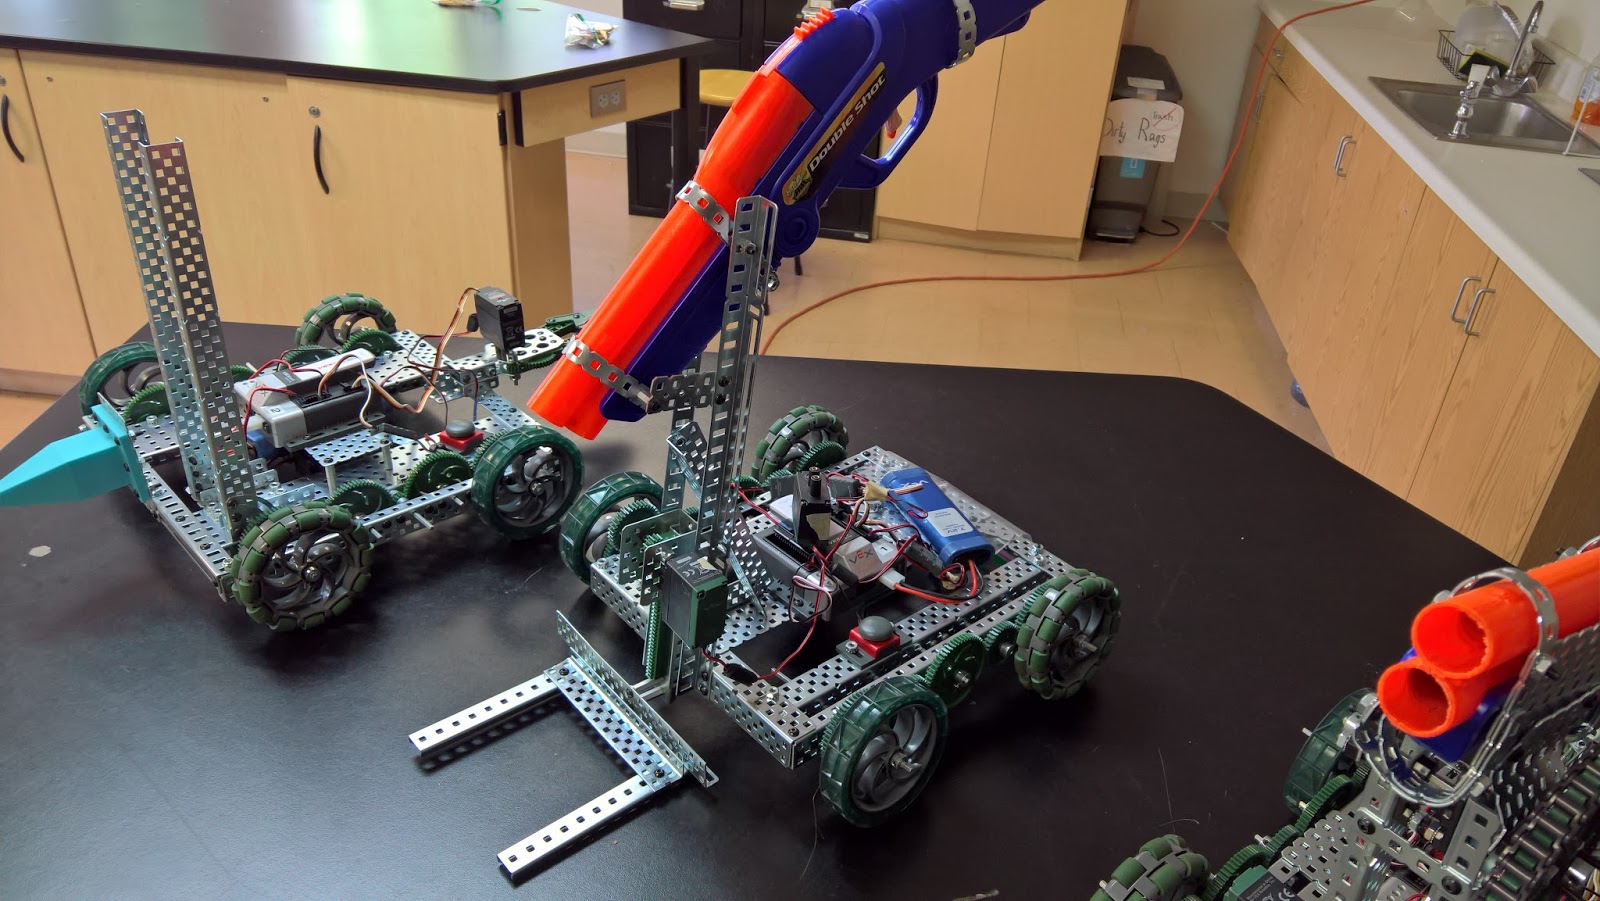 |
| The forklift and fixed disruptor are now clearly visible |
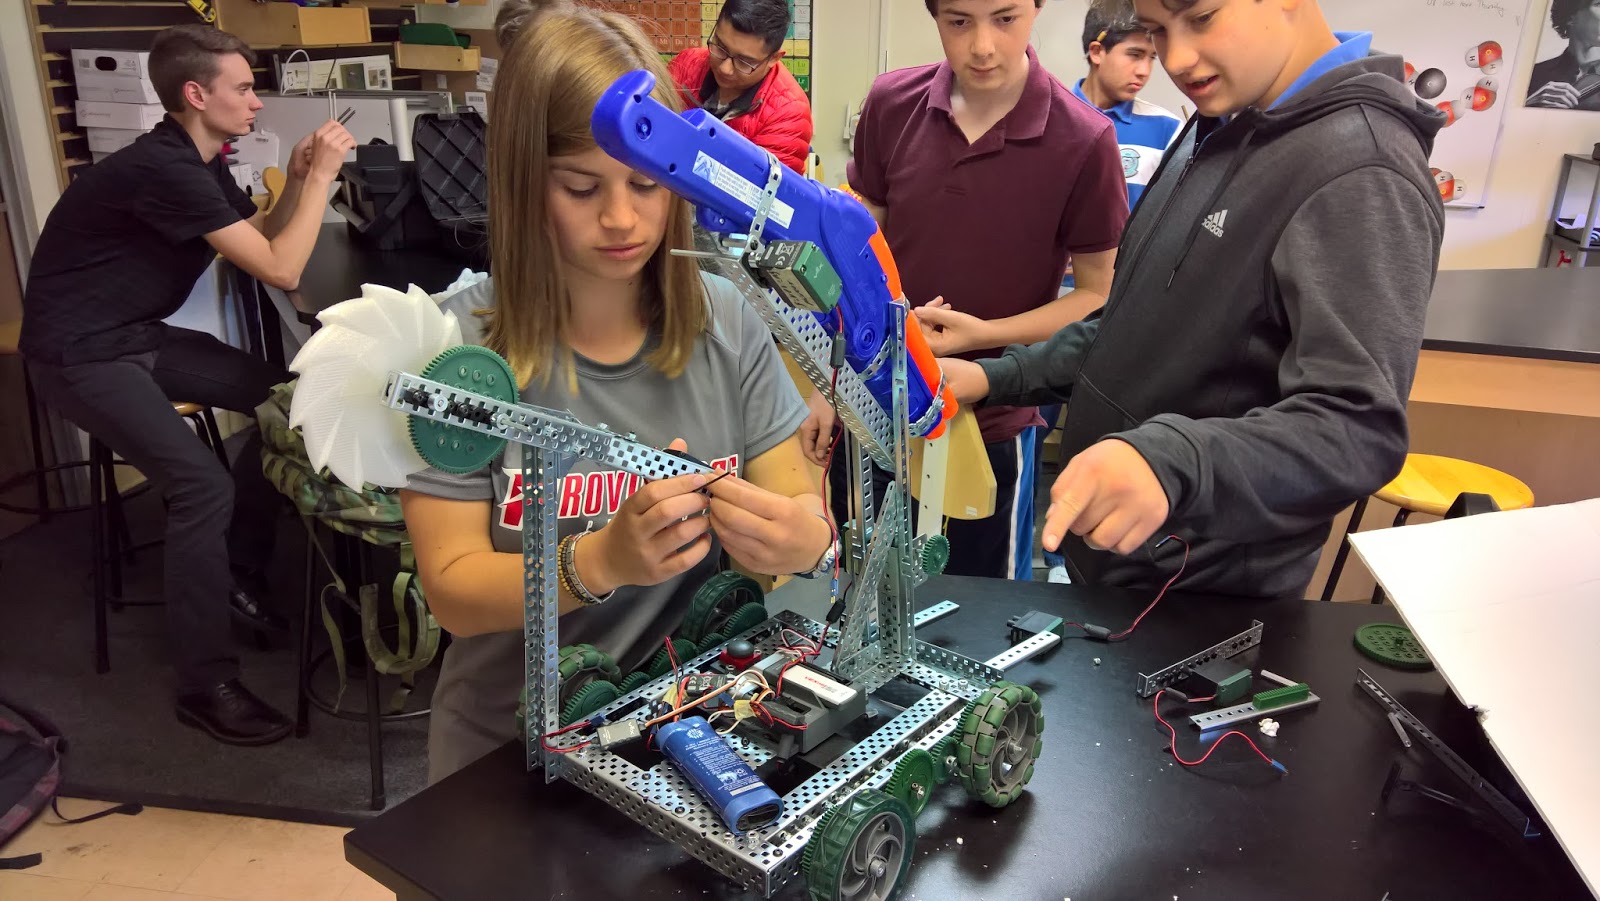 |
| Claire works to add in the 3D-printed circular saw |
 |
| Yes, this actually did work! (Slowly…) |
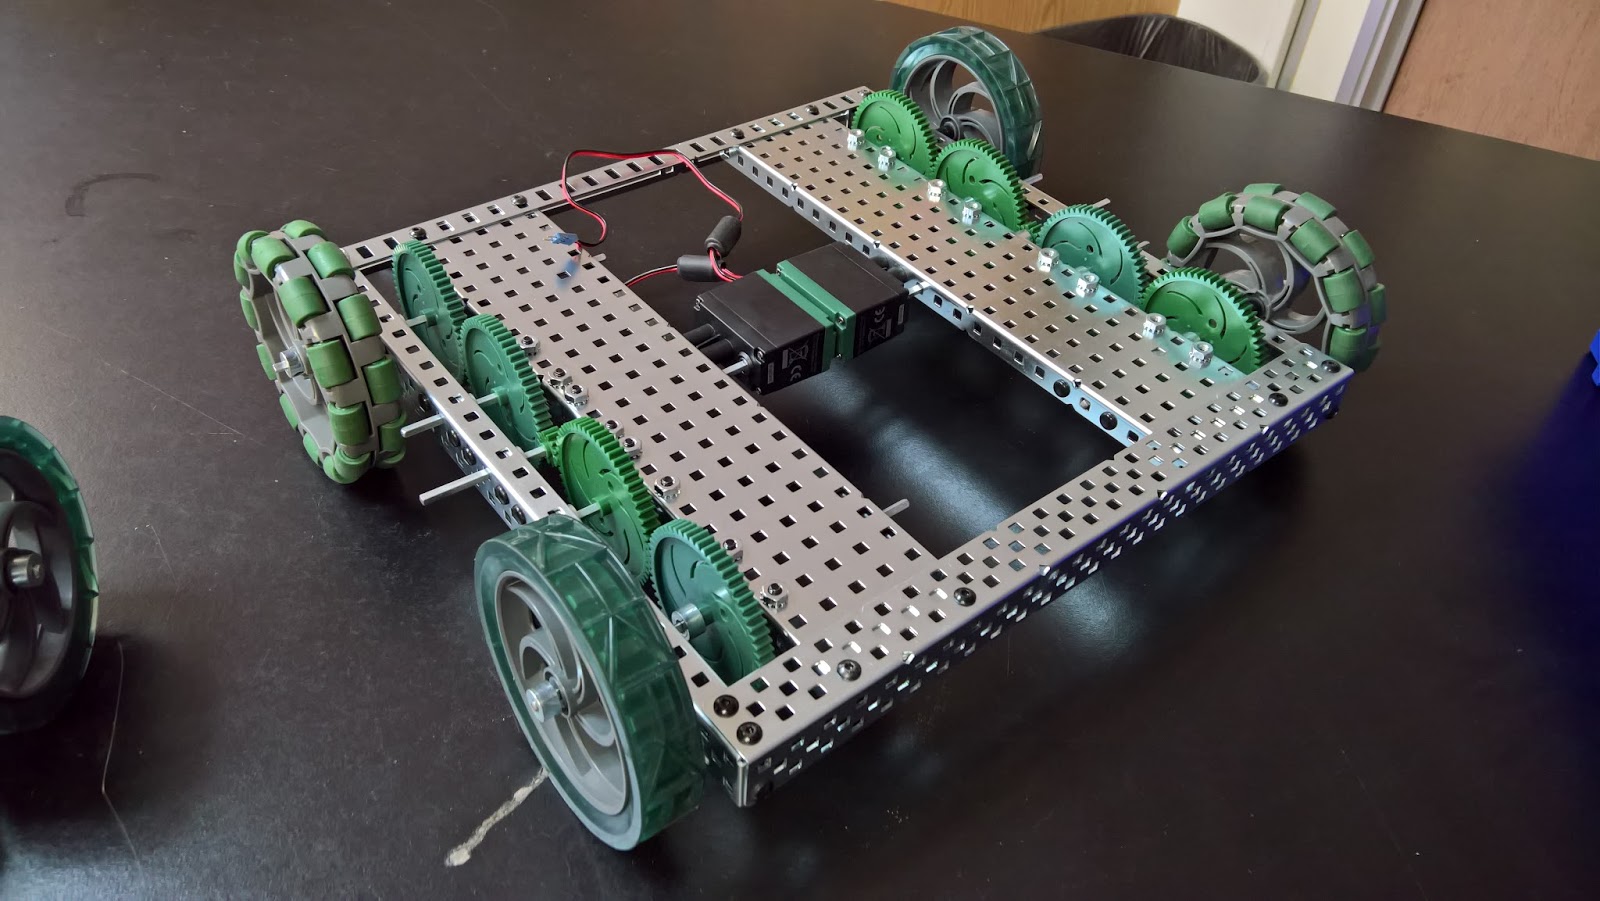 |
The early days of Josh’s team’s design, with the highest torque to the wheels of any team (the tiny gear coming from the black motors to the large gears at the wheels ensures this) |
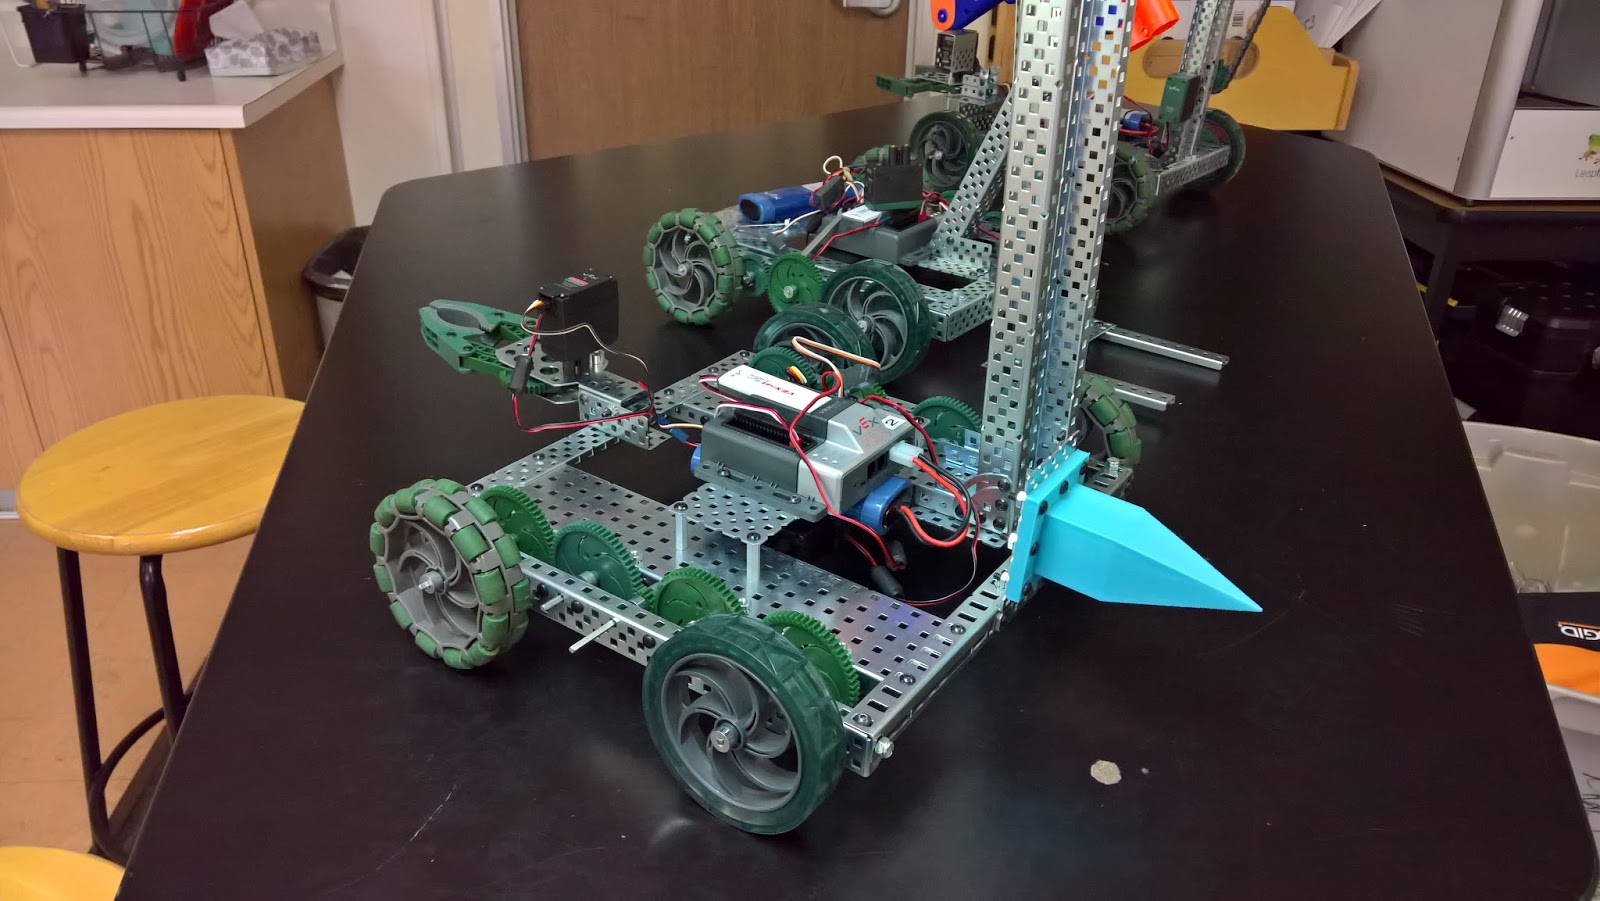 |
Later on, a manipulator claw was added, as well as a powerful spike, designed by Alec |
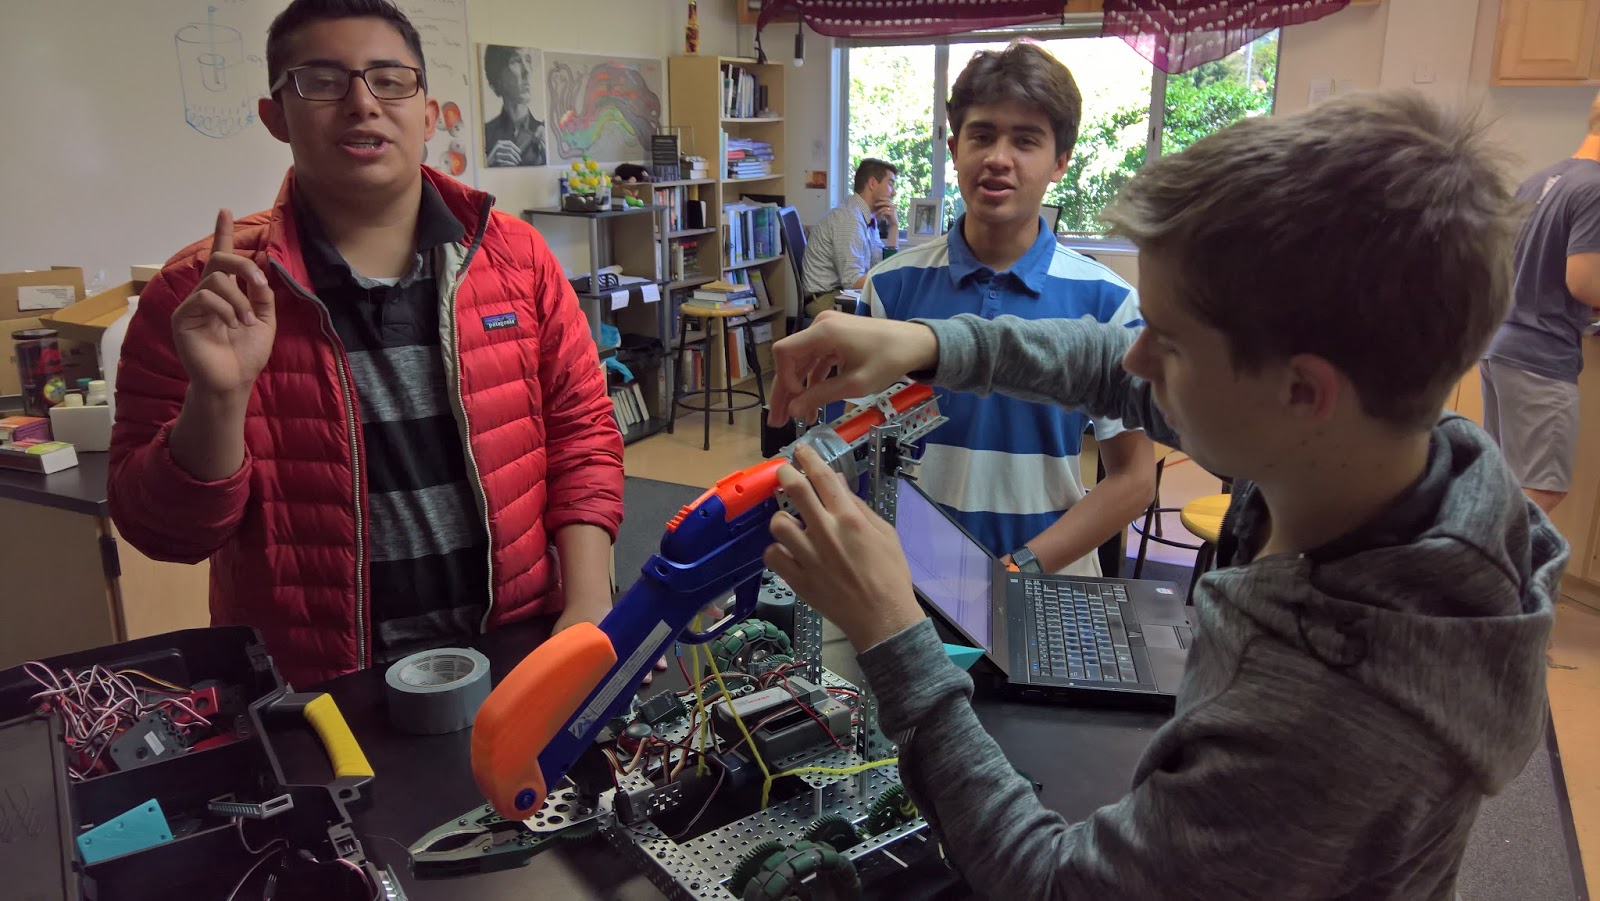 |
Josh instructs his team in proper safety protocol, as Victor looks and Alec attaches the disruptor |
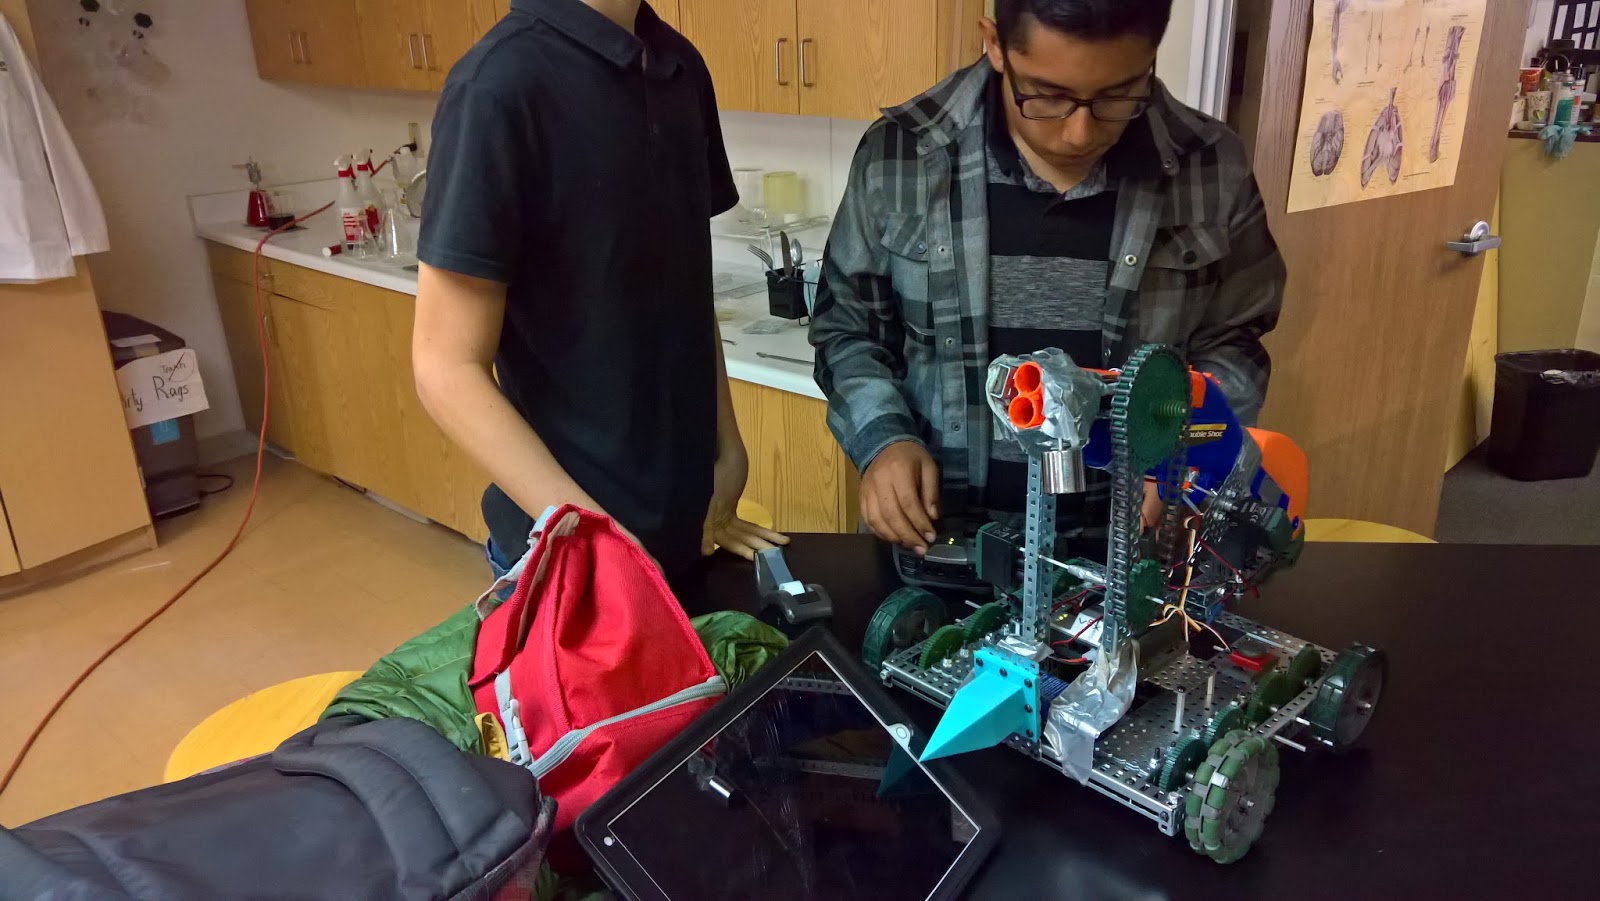 |
| The final stages, with a chain drive now added to the disruptor |
 |
The frame and foamboard door; note the hot pink 3D-printed working hinges and deadbolt, courtesy of Kylie’s design skills |
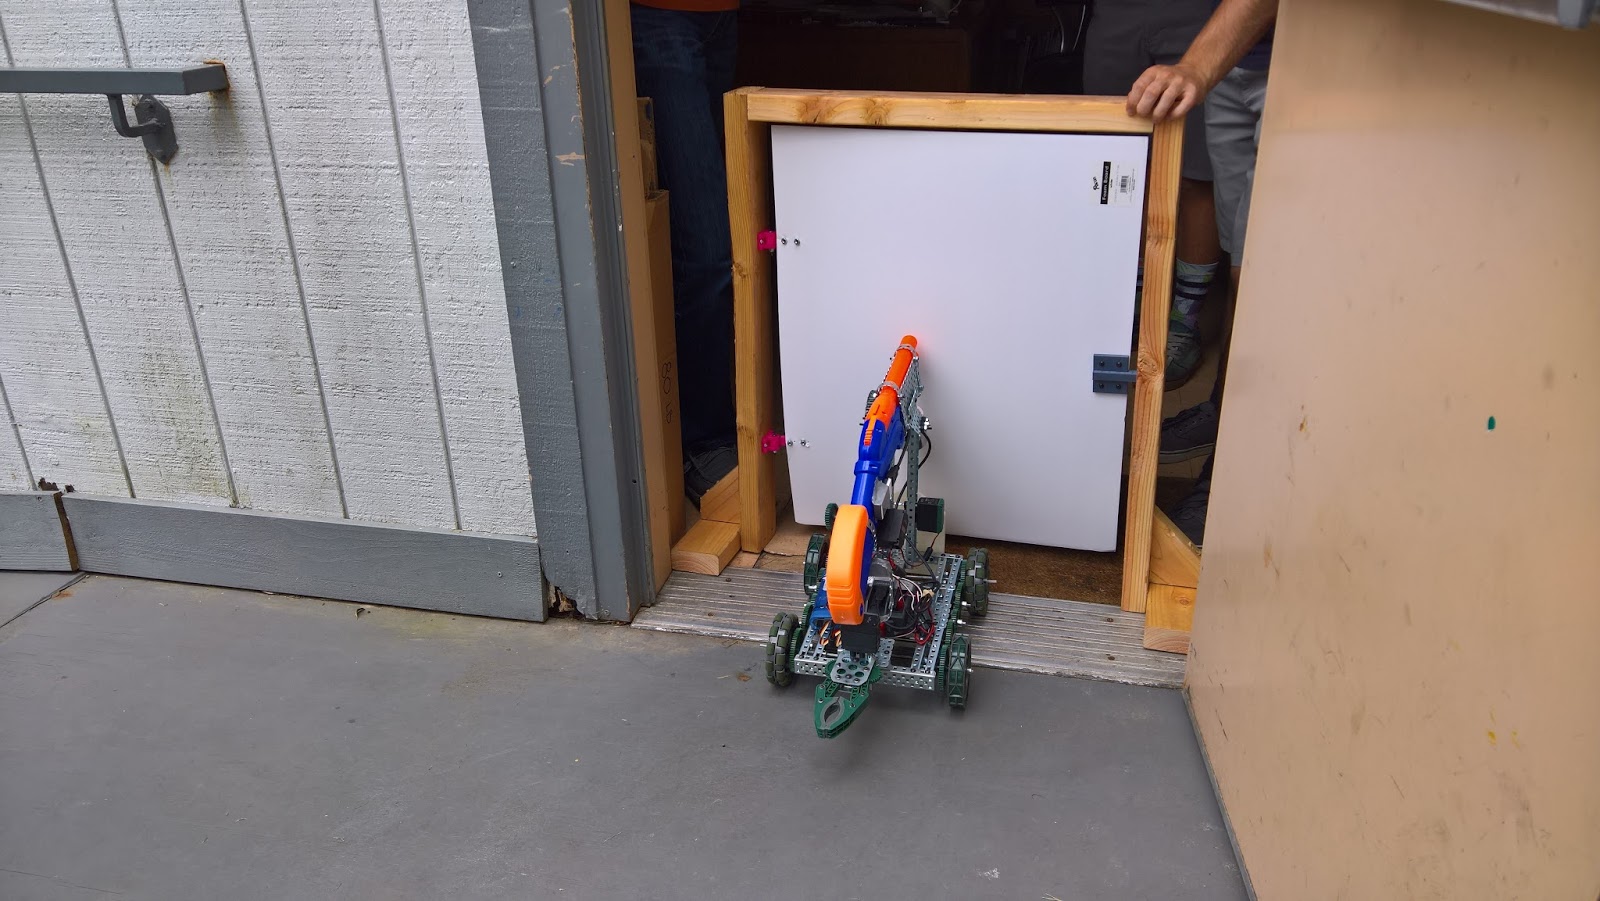 |
Eva’s team attempts to push through the door with brute force and the “wedge” principle |
 |
Alena’s team gets ready to cut through the door; note the cyan spike added to the rear as a backup plan |
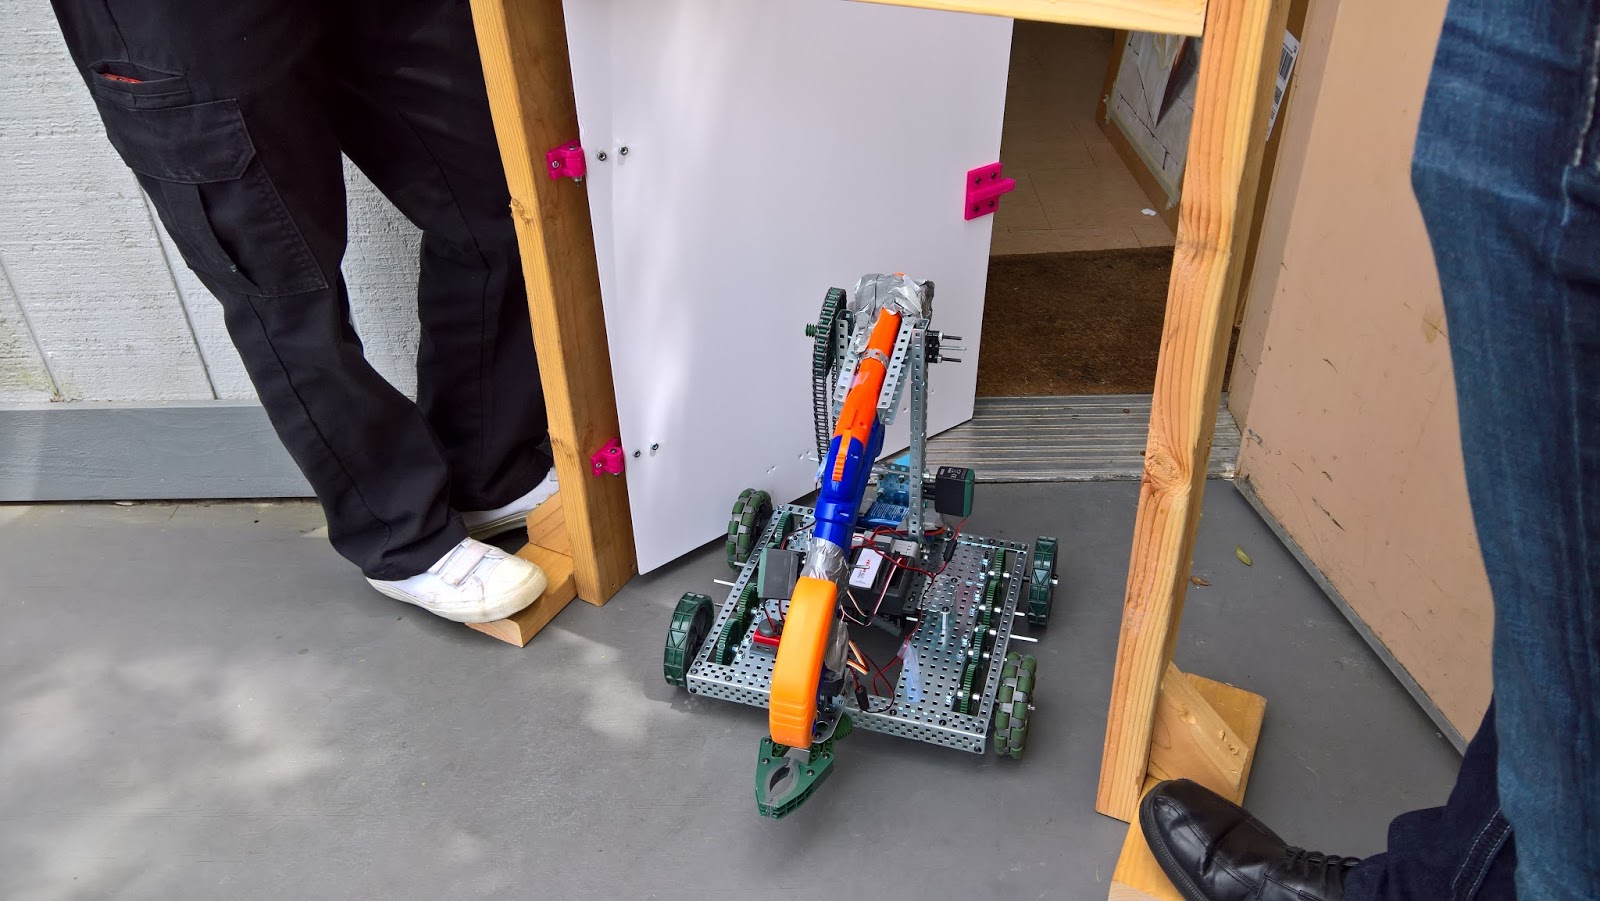 |
| Josh’s team pushes through quickly with a simple spike |
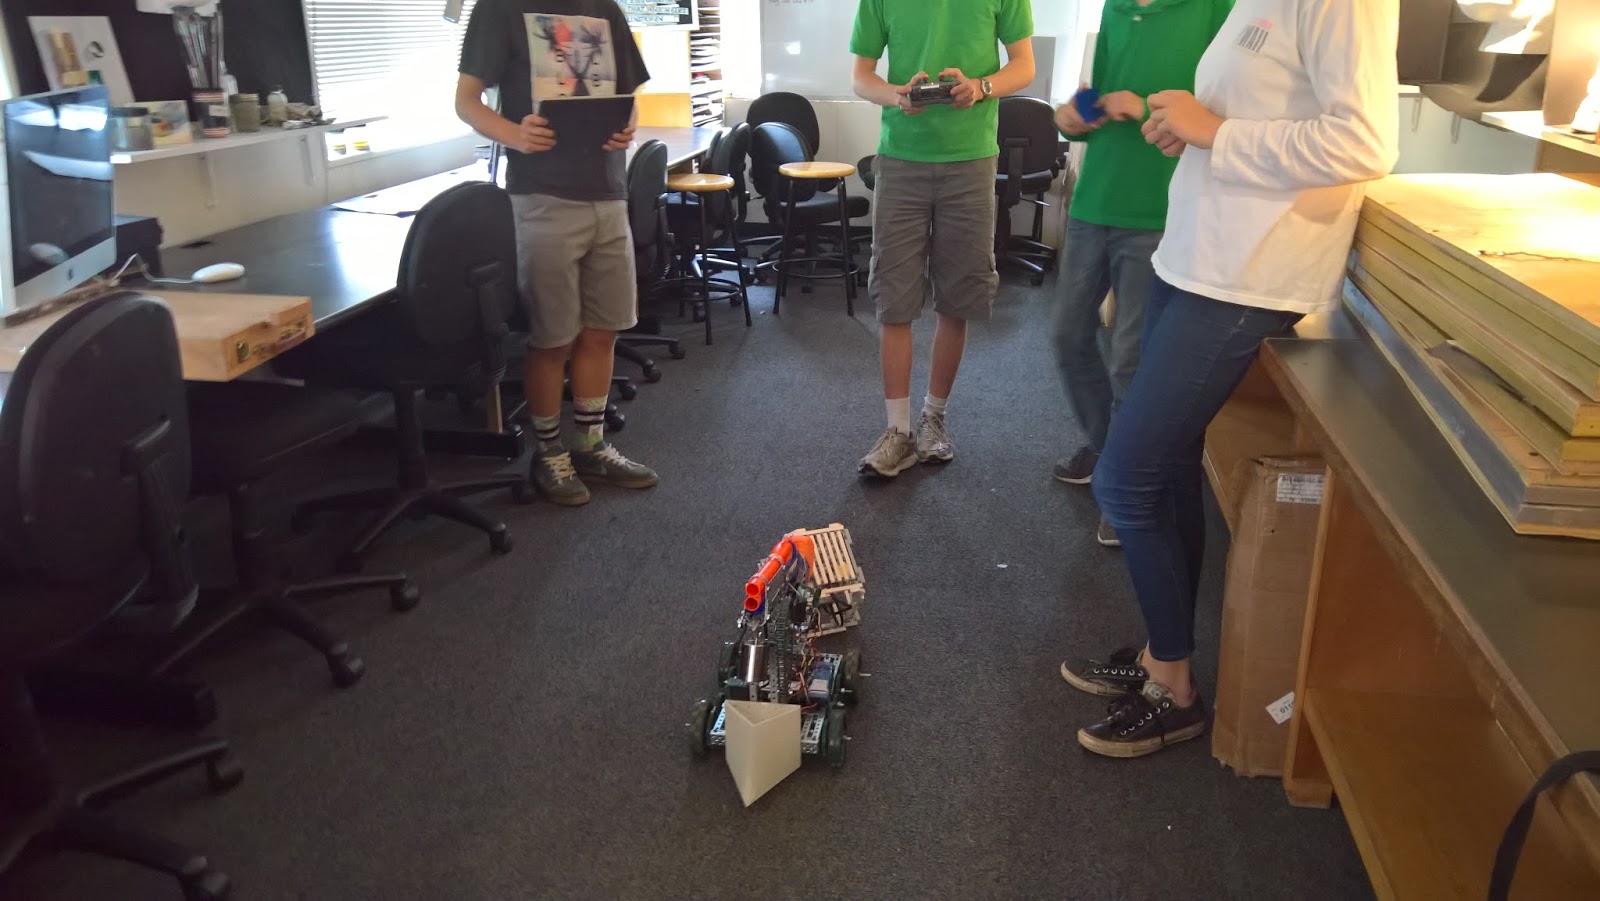 |
Eva’s team drags the bomb cautiously away towards the door, Colby at the wheel |
 |
Alena’s team’s unique forklift method worked perfectly, deftly carrying the bomb to the exit |
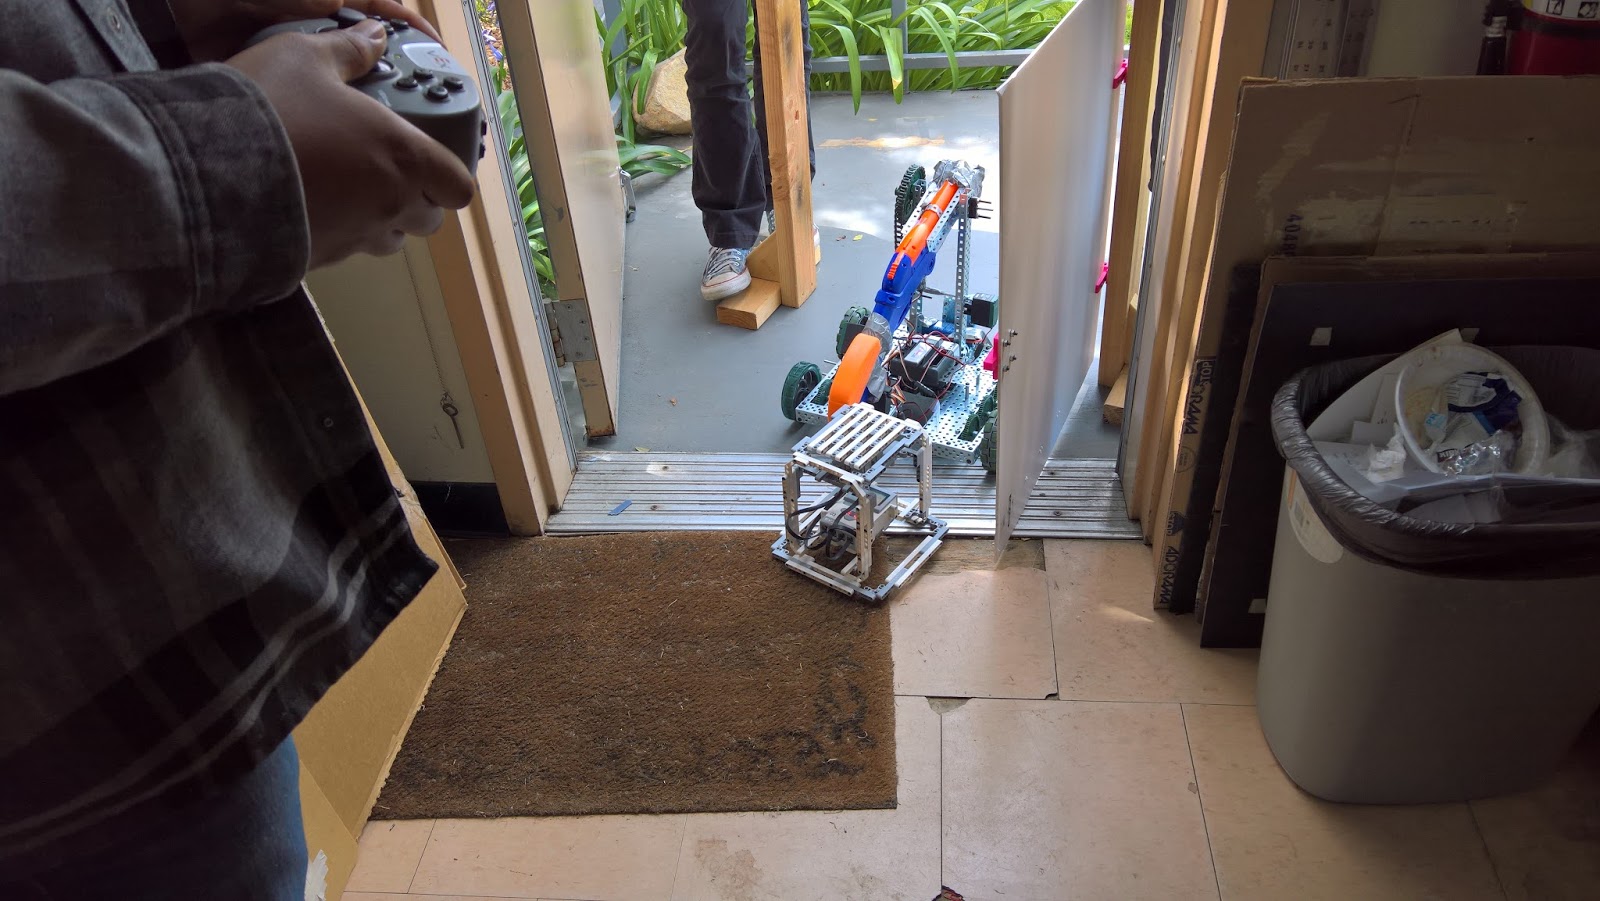 |
Josh’s team pulls the bomb over some tricky terrain and back through the door |
With the bomb safely outside away from civilians, the robots aimed their air-powered disruptors at the bomb. This is a real tactic that bomb disposal robots use; the idea is that a quick blast from a shotgun shell should immediately destroy all triggers and batteries and other mechanisms, thereby preventing the actual detonation.
Eva’s group and Alena’s group took a few shots to disarm the bomb (the trigger plate didn’t “feel” their bullets enough to switch off), and Josh’s team got it first try!
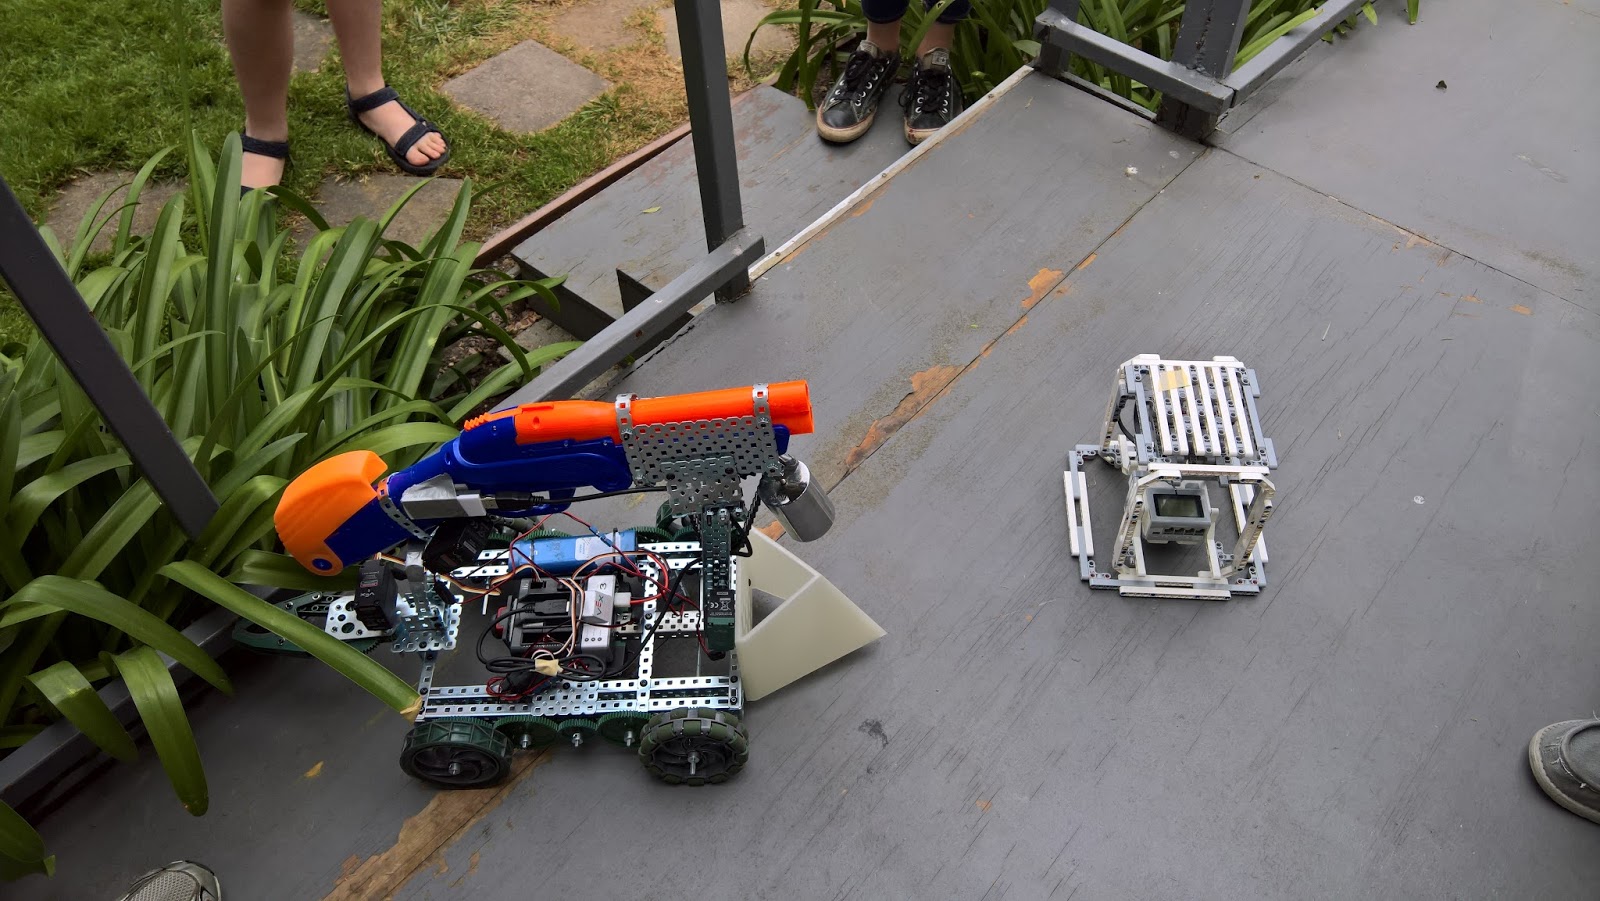 |
| Eva’s team squares up, trying to find the best angle |
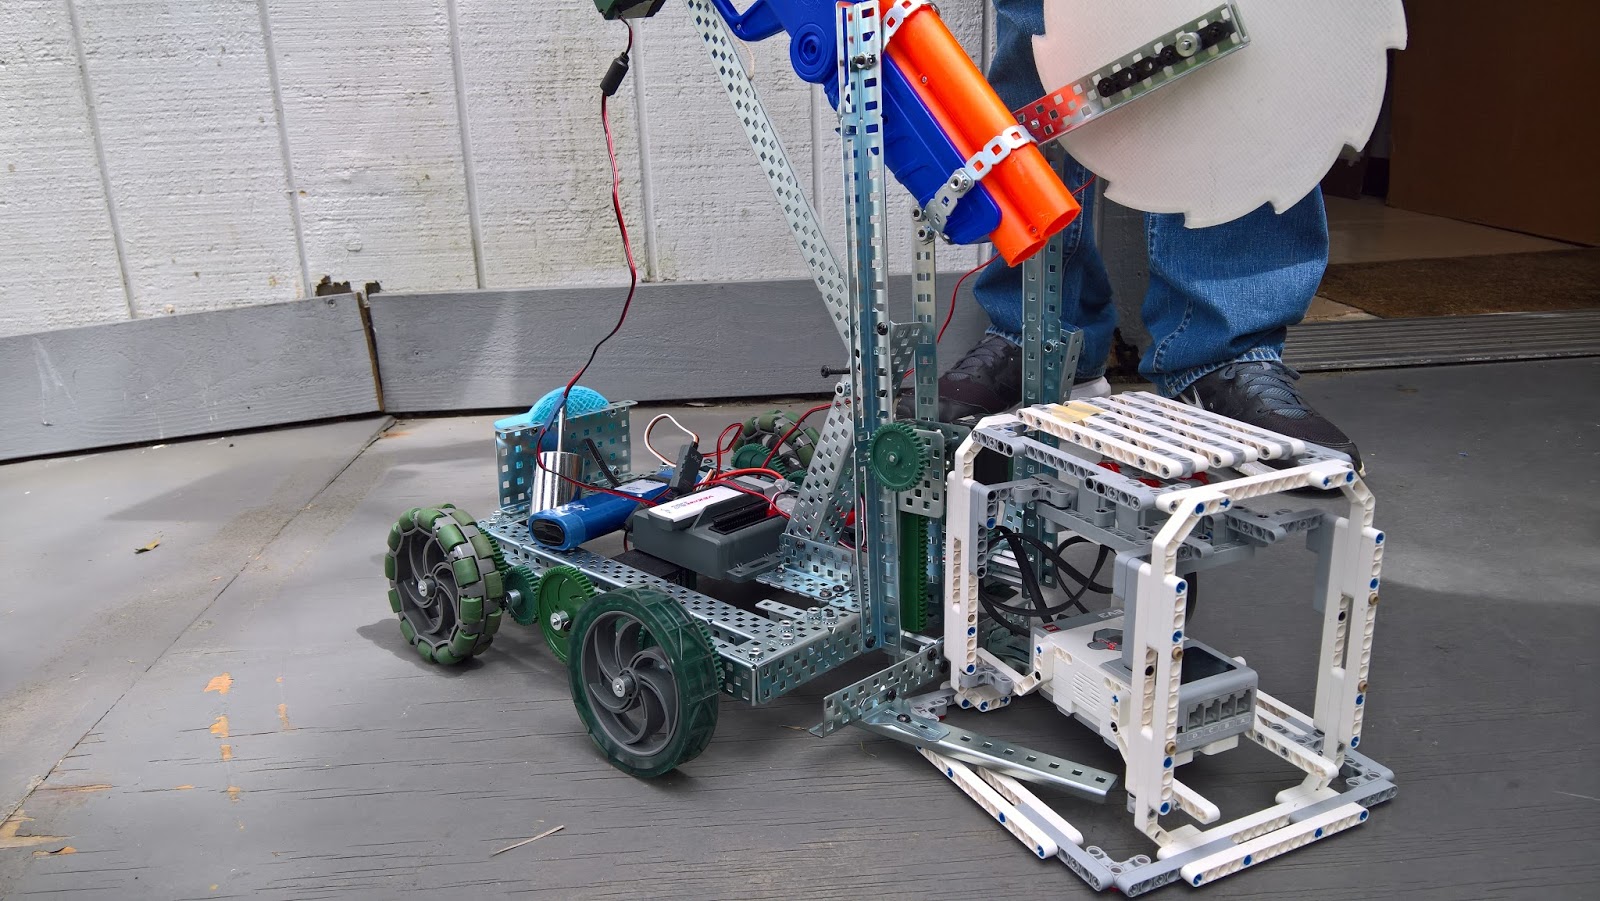 |
| Alena’s team hugs the package tightly, and goes in for the finish |
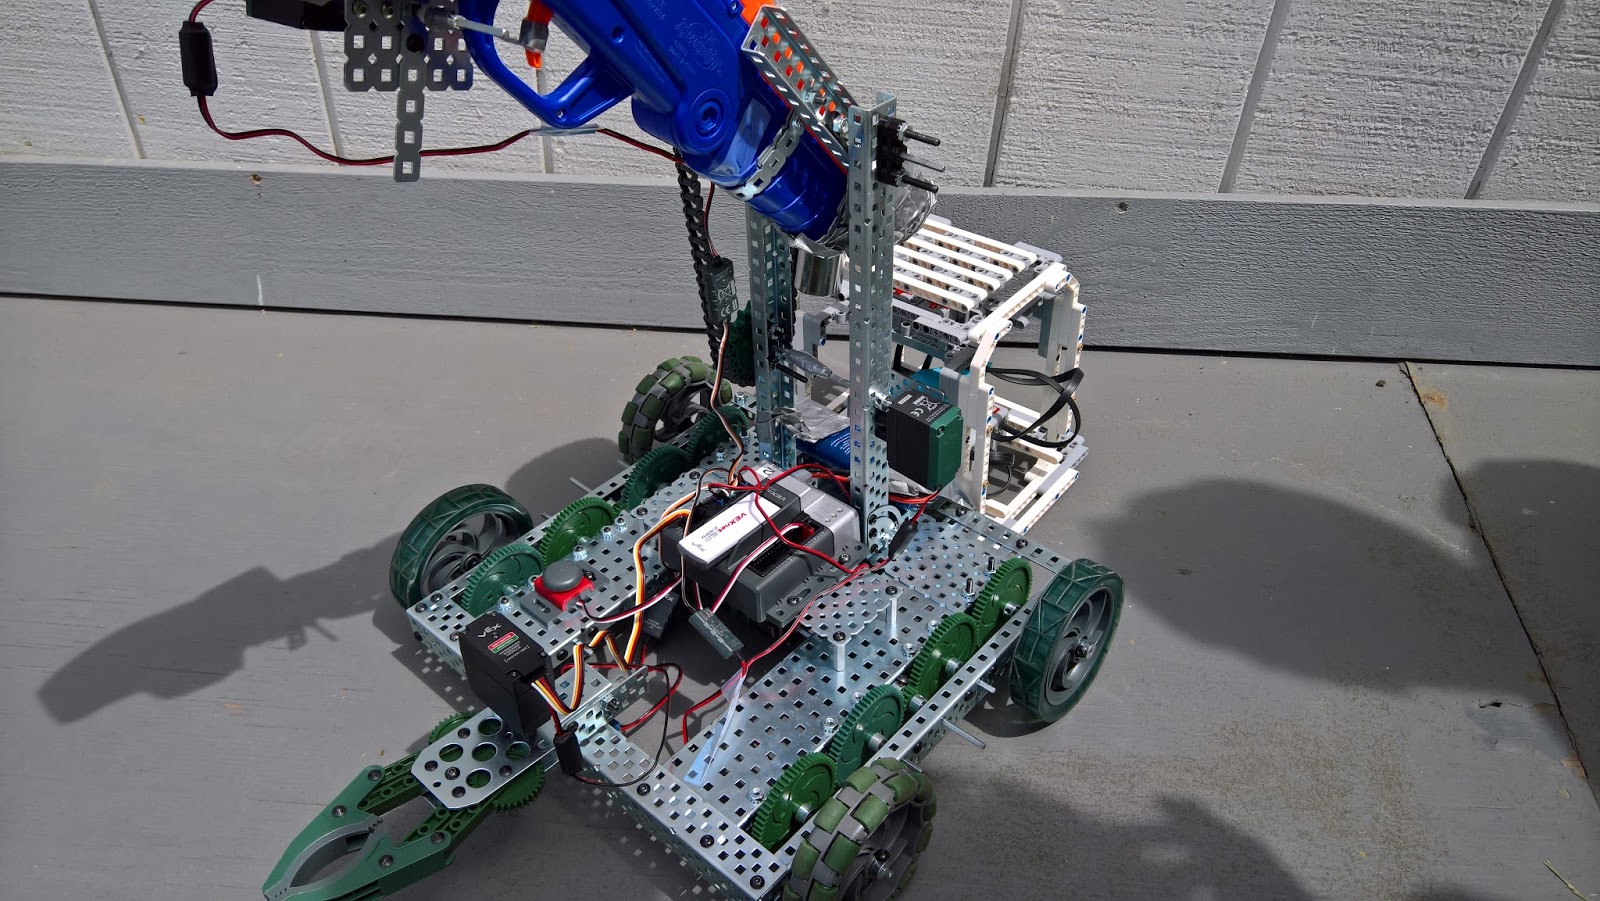 |
| Josh’s team readies, aims, and fires! |
 |
| Eva, David, Colby, and Todd celebrate a job well done! |
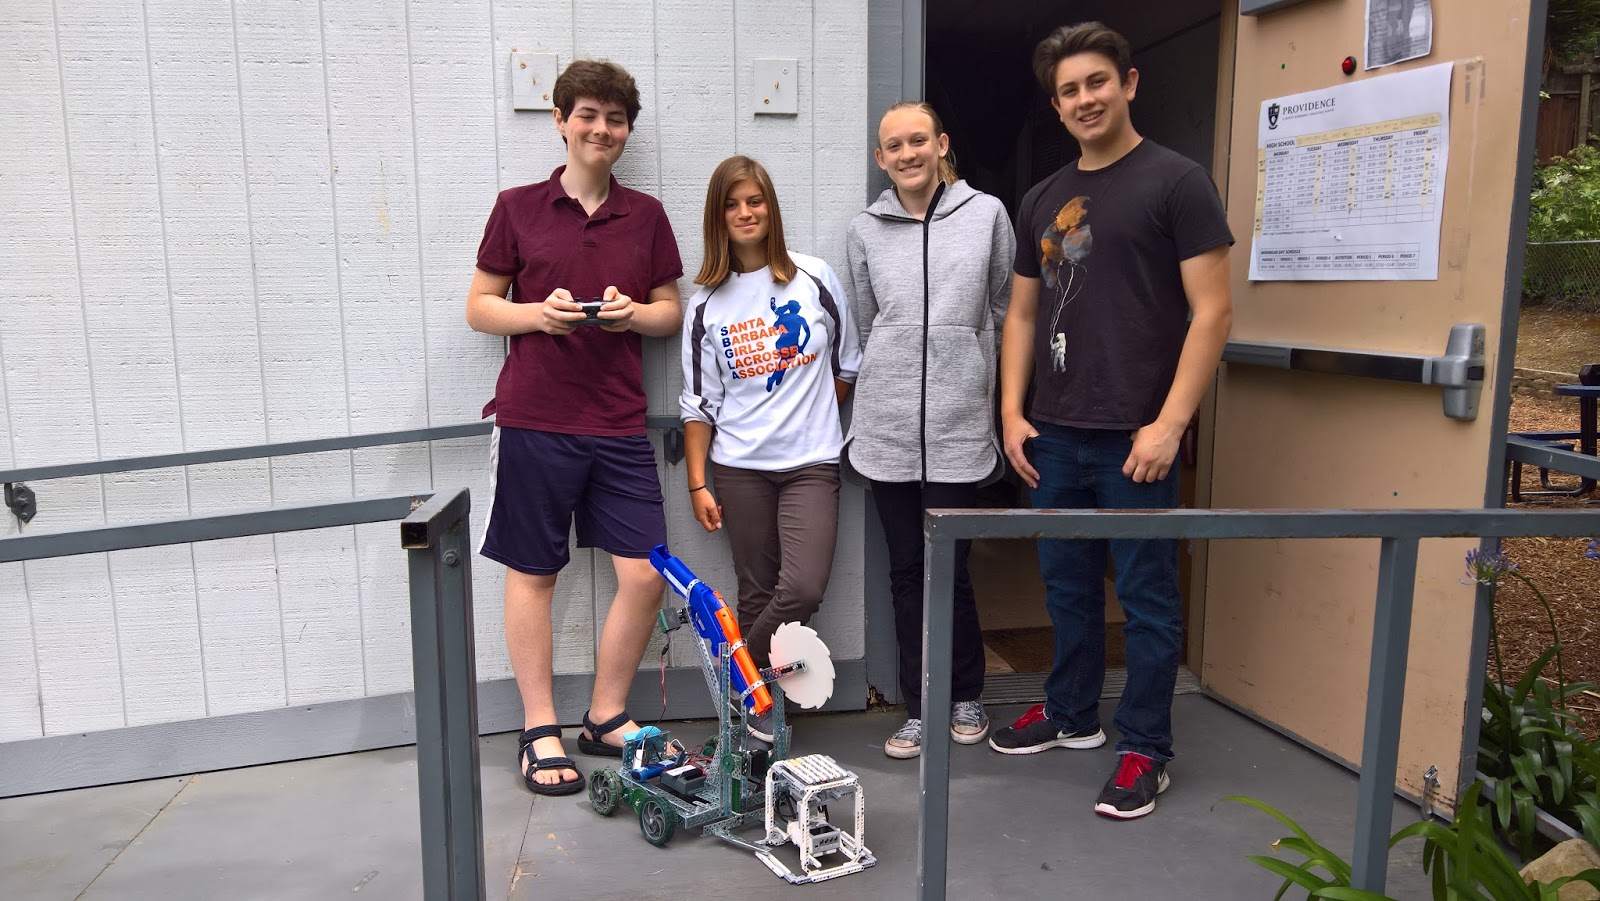 |
| Jakob, Claire, Alena, and Samy proudly pose behind their robot |
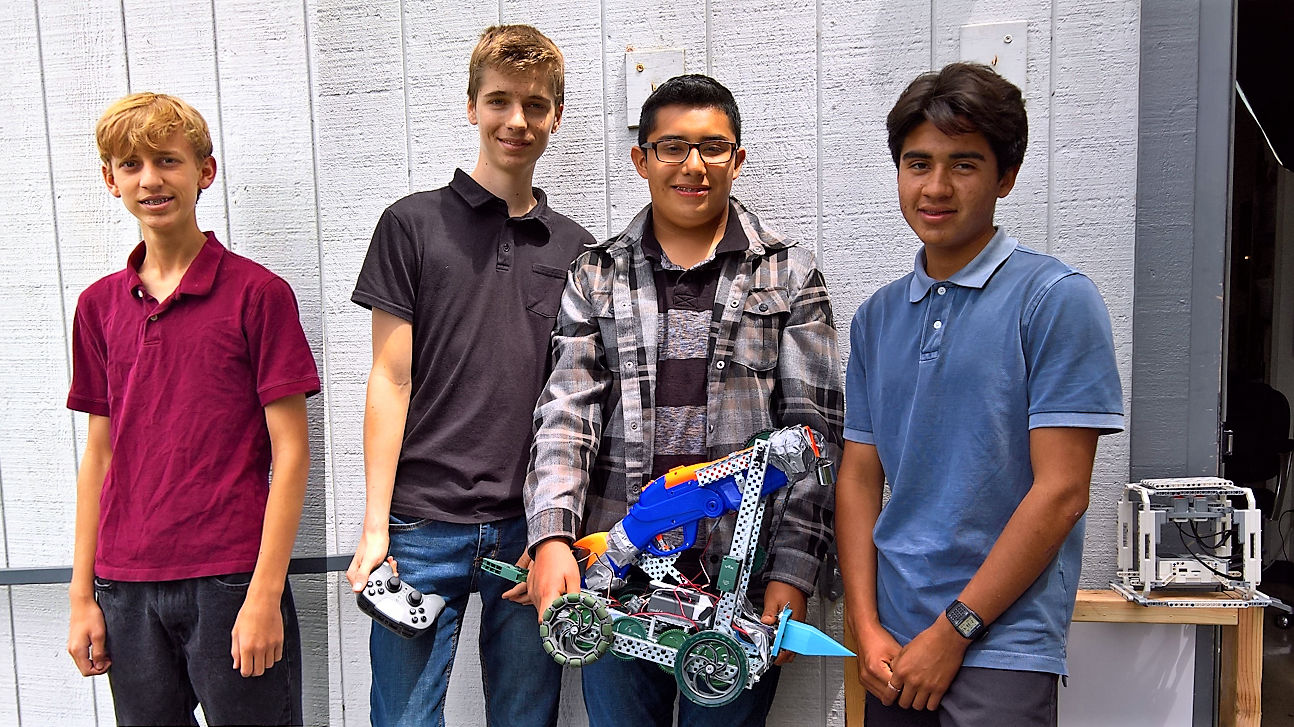 |
| Ben, Alec, Josh, and Victor enjoy a job well done |
All teams are to be congratulated on a solid, successful performance. The growth exhibited by these students throughout the year is phenomenal–where they once were fumbling with the most basic code lines and how to attach pieces, they now moved through it swiftly and expertly, with a minimum of guidance from the teacher. No teams suffered critical failure, as some had on previous projects, and it was a delight to see the hard work paying off.
If you want to watch the entire play in action, please access them in this shared folder. You are welcome to download or watch online–the videos of each team are over ten minutes long!
Excellent work all, and we’ll see you next year!
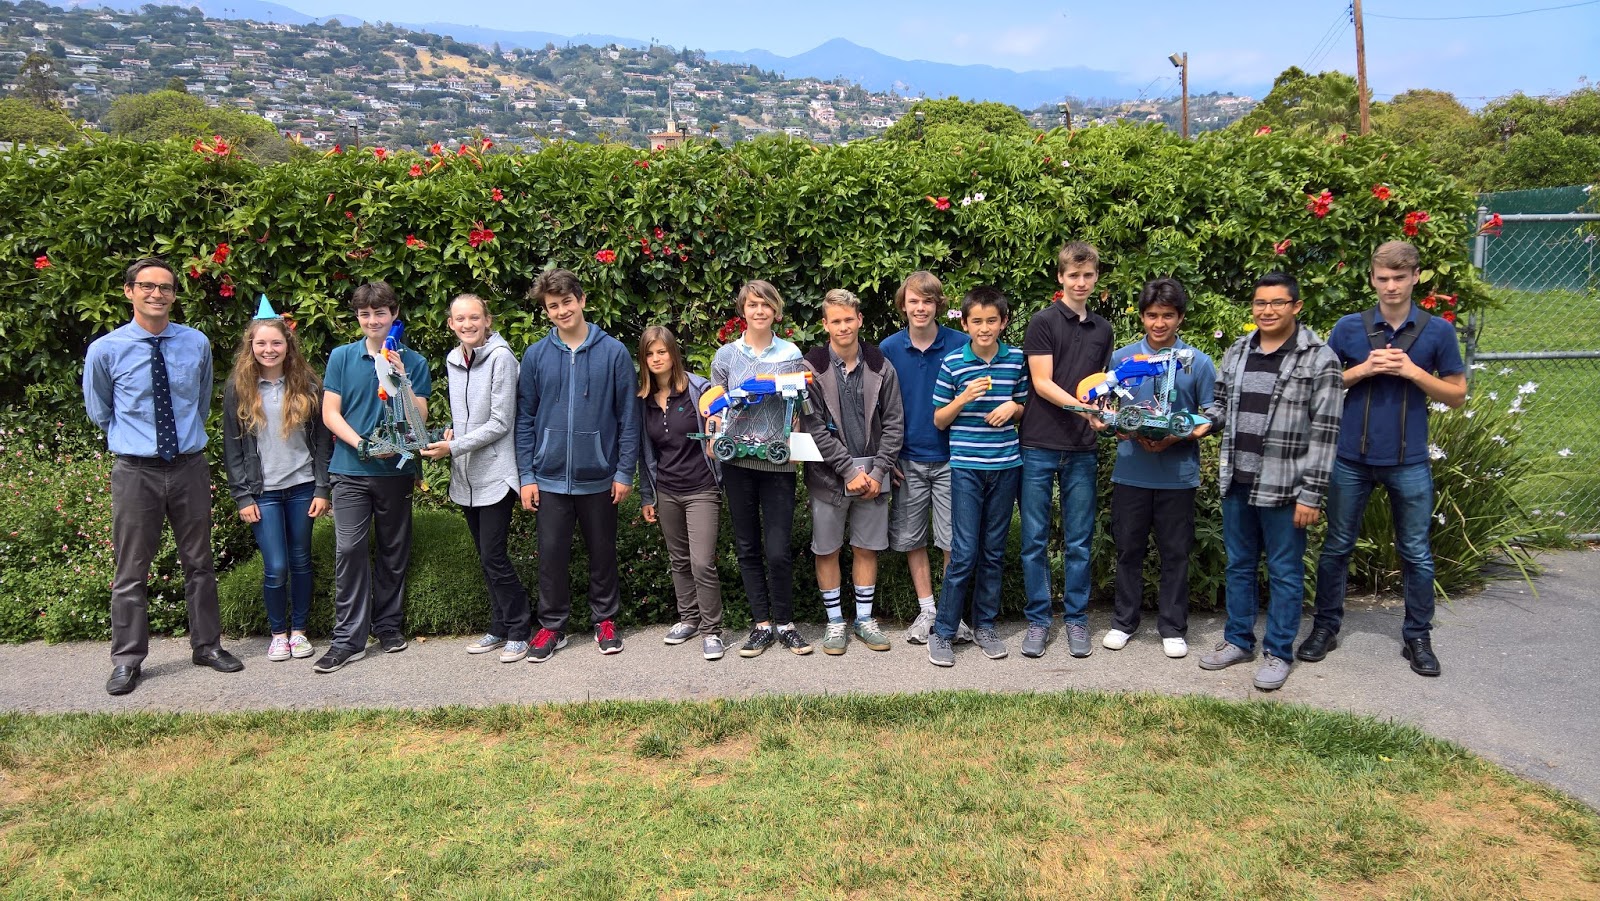 |
From left to right: Mr. Meadth, Kylie (T.A.), Jakob, Alena, Samy, Claire, Eva, David, Colby, Todd, Alec, Victor, Josh, Aaron (T.A.); (Ben absent) |